Publications & Research
Peer-reviewed journal articles, conference papers, and robotics project websites.
IROS '26
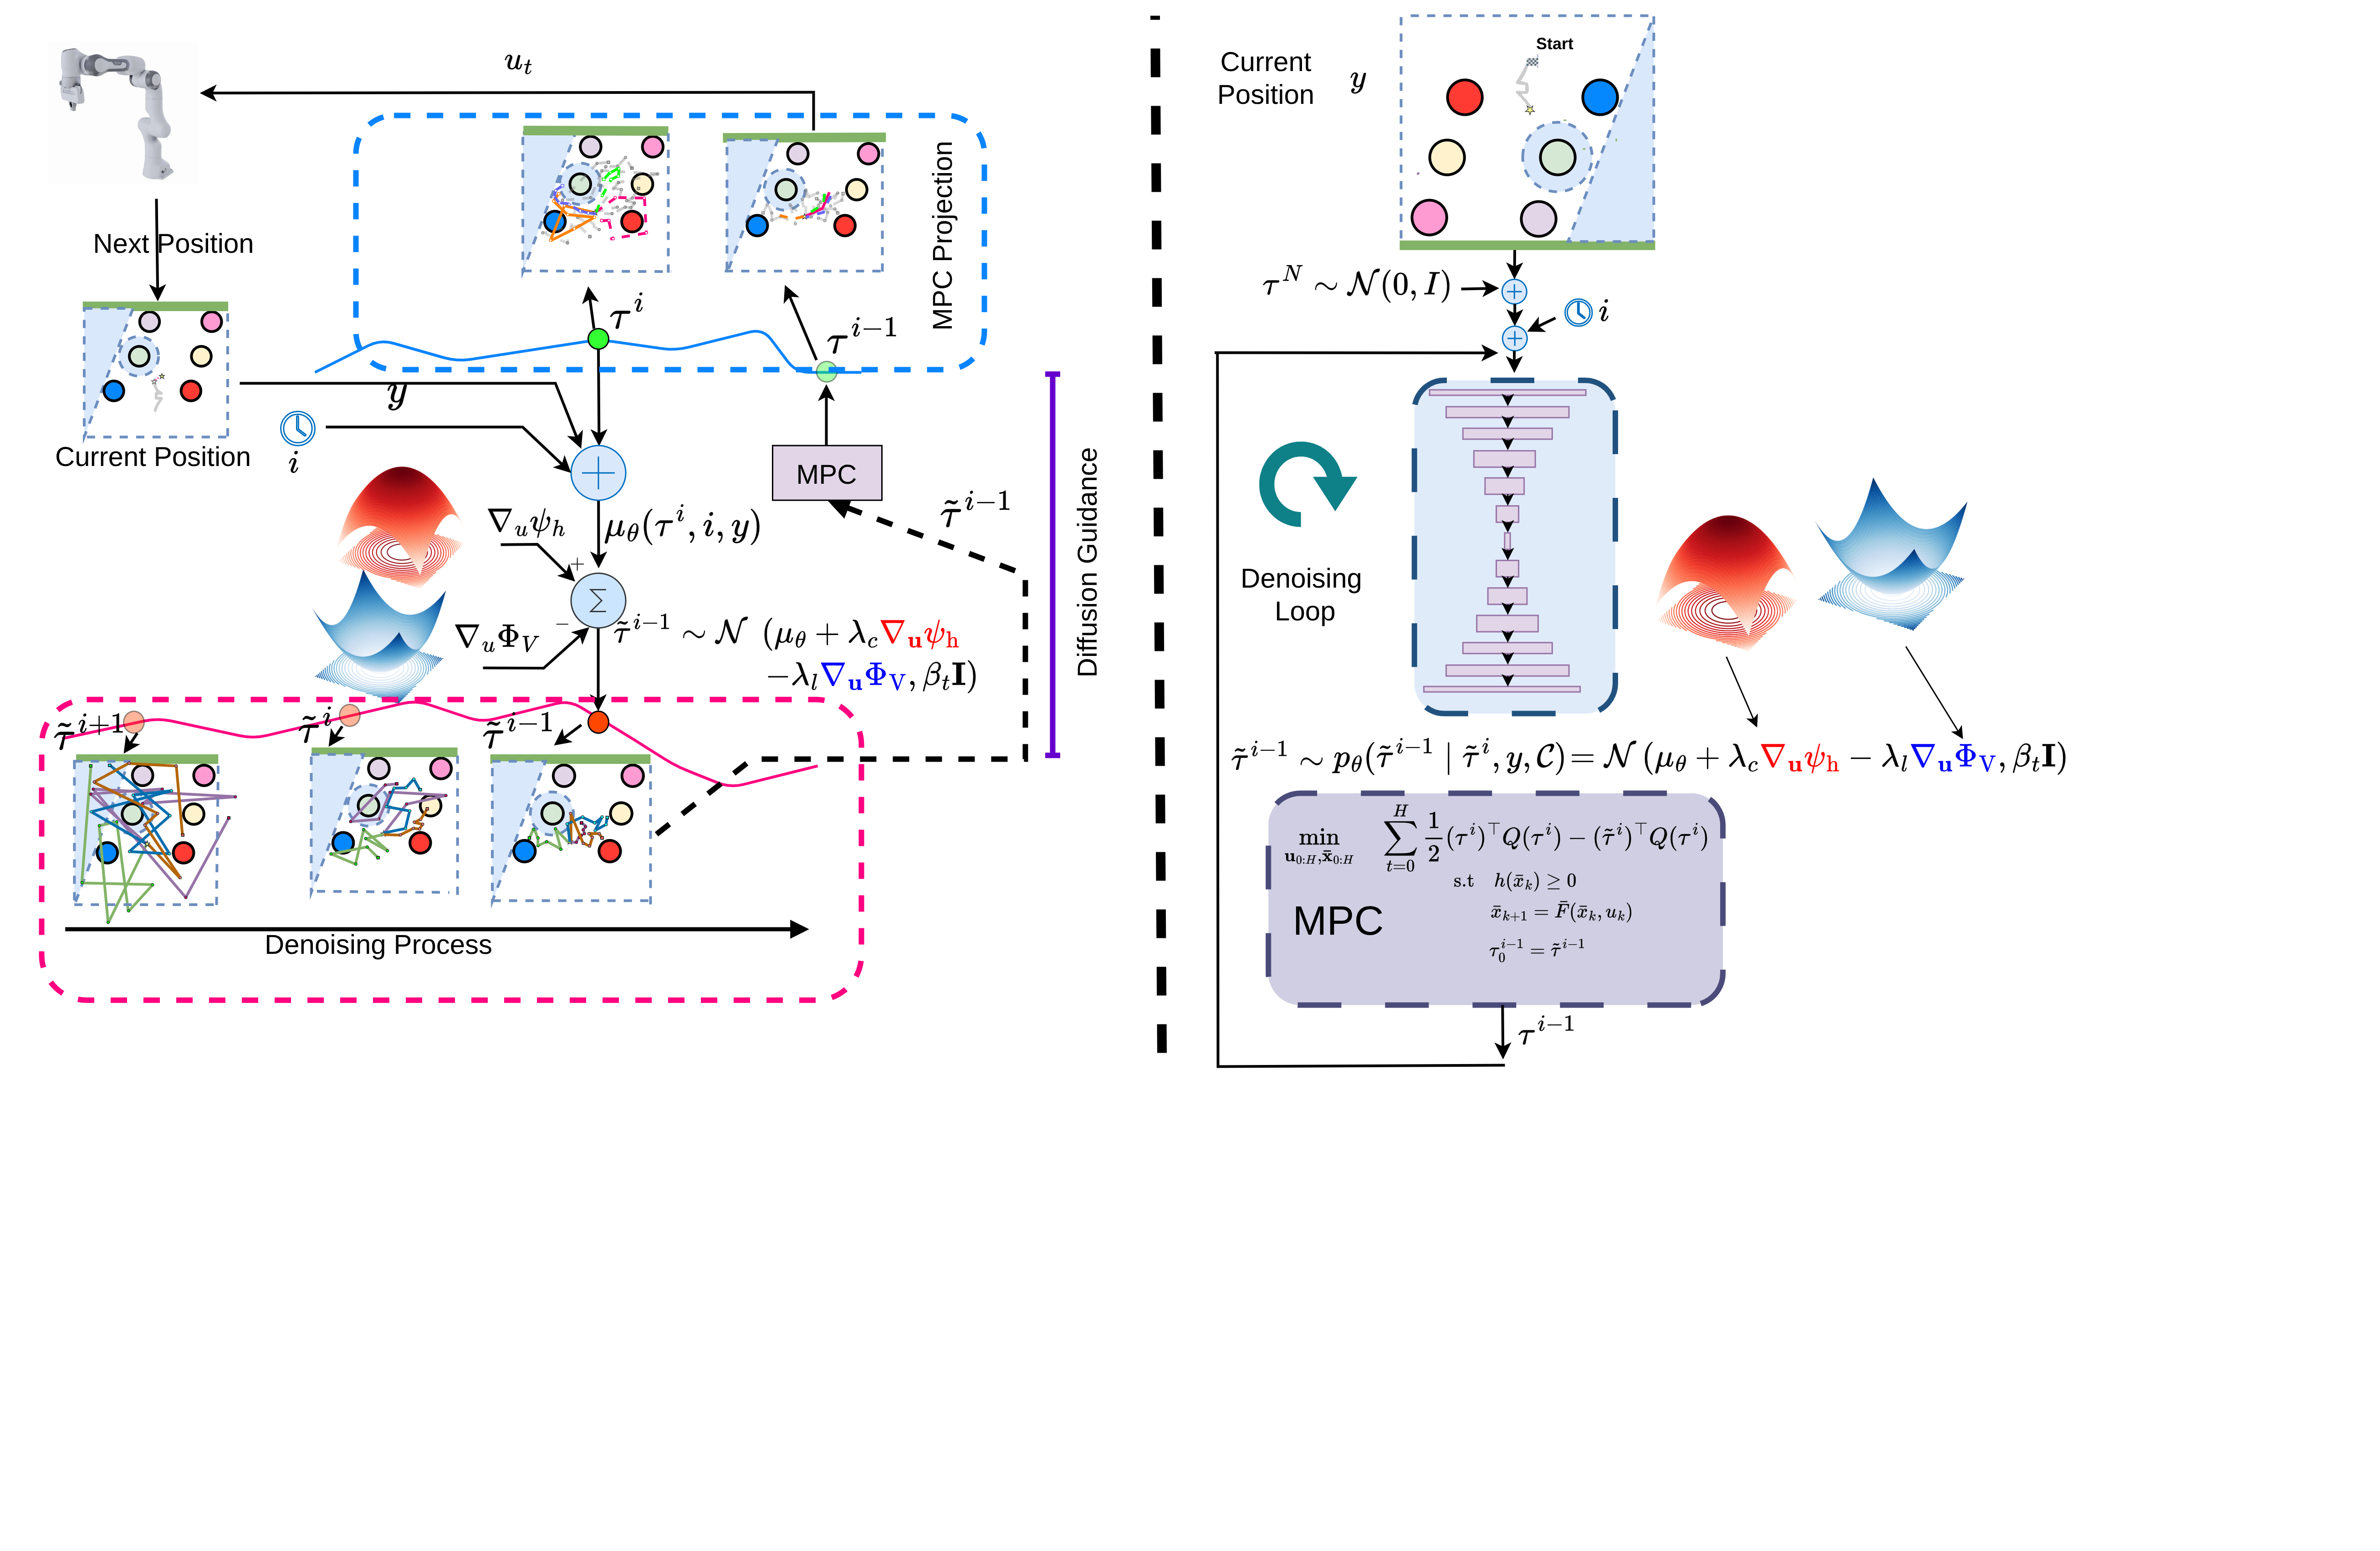
D-SafeMPC: Diffusion-Driven Safe Model Predictive Control with Discrete-Time Control Barrier Functions
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Pittsburgh, 2026
A unified framework coupling discrete-time CBF and CLF-guided reverse diffusion with iterative-projection MPC for safe robot trajectory generation under dynamic constraints, validated on a physical 7-DOF Franka manipulator.
WCCI '26
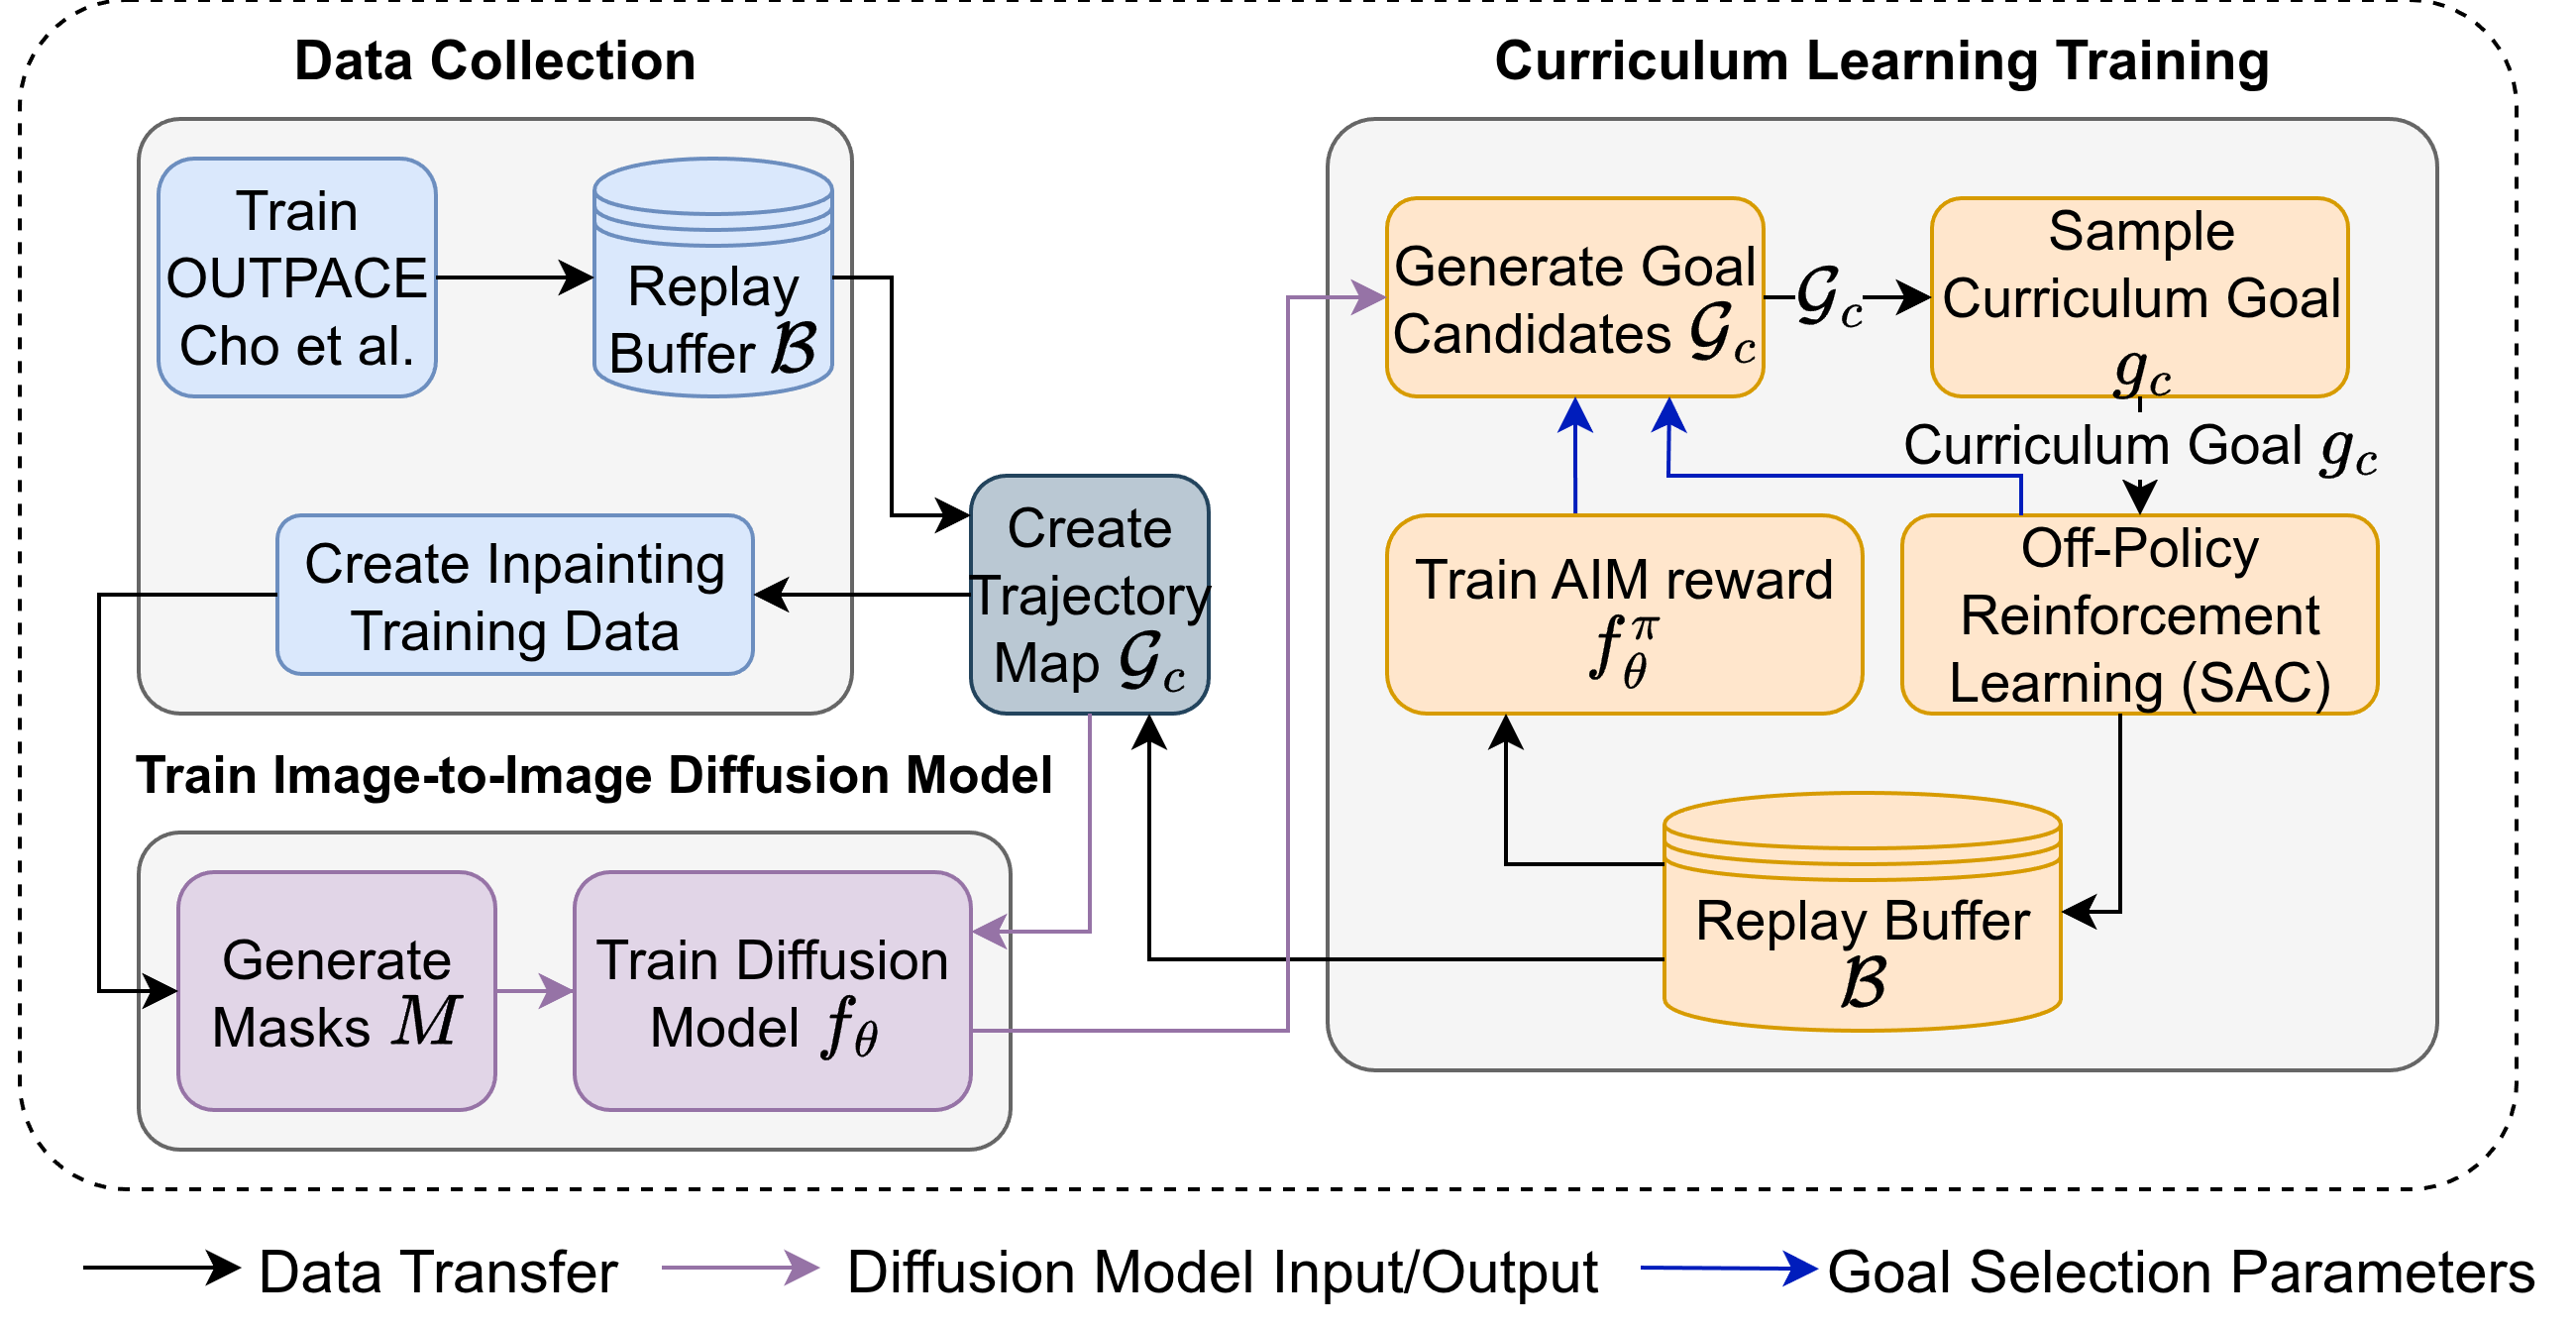
Palette Inpainting Diffusion Curriculum Reinforcement Learning (PIDCRL)
IEEE World Congress on Computational Intelligence (WCCI), 2026
A diffusion-based CRL framework that adapts mask-conditional image inpainting on trajectory heatmaps to automatically generate achievable, progressively challenging curriculum goals.
WCCI '26
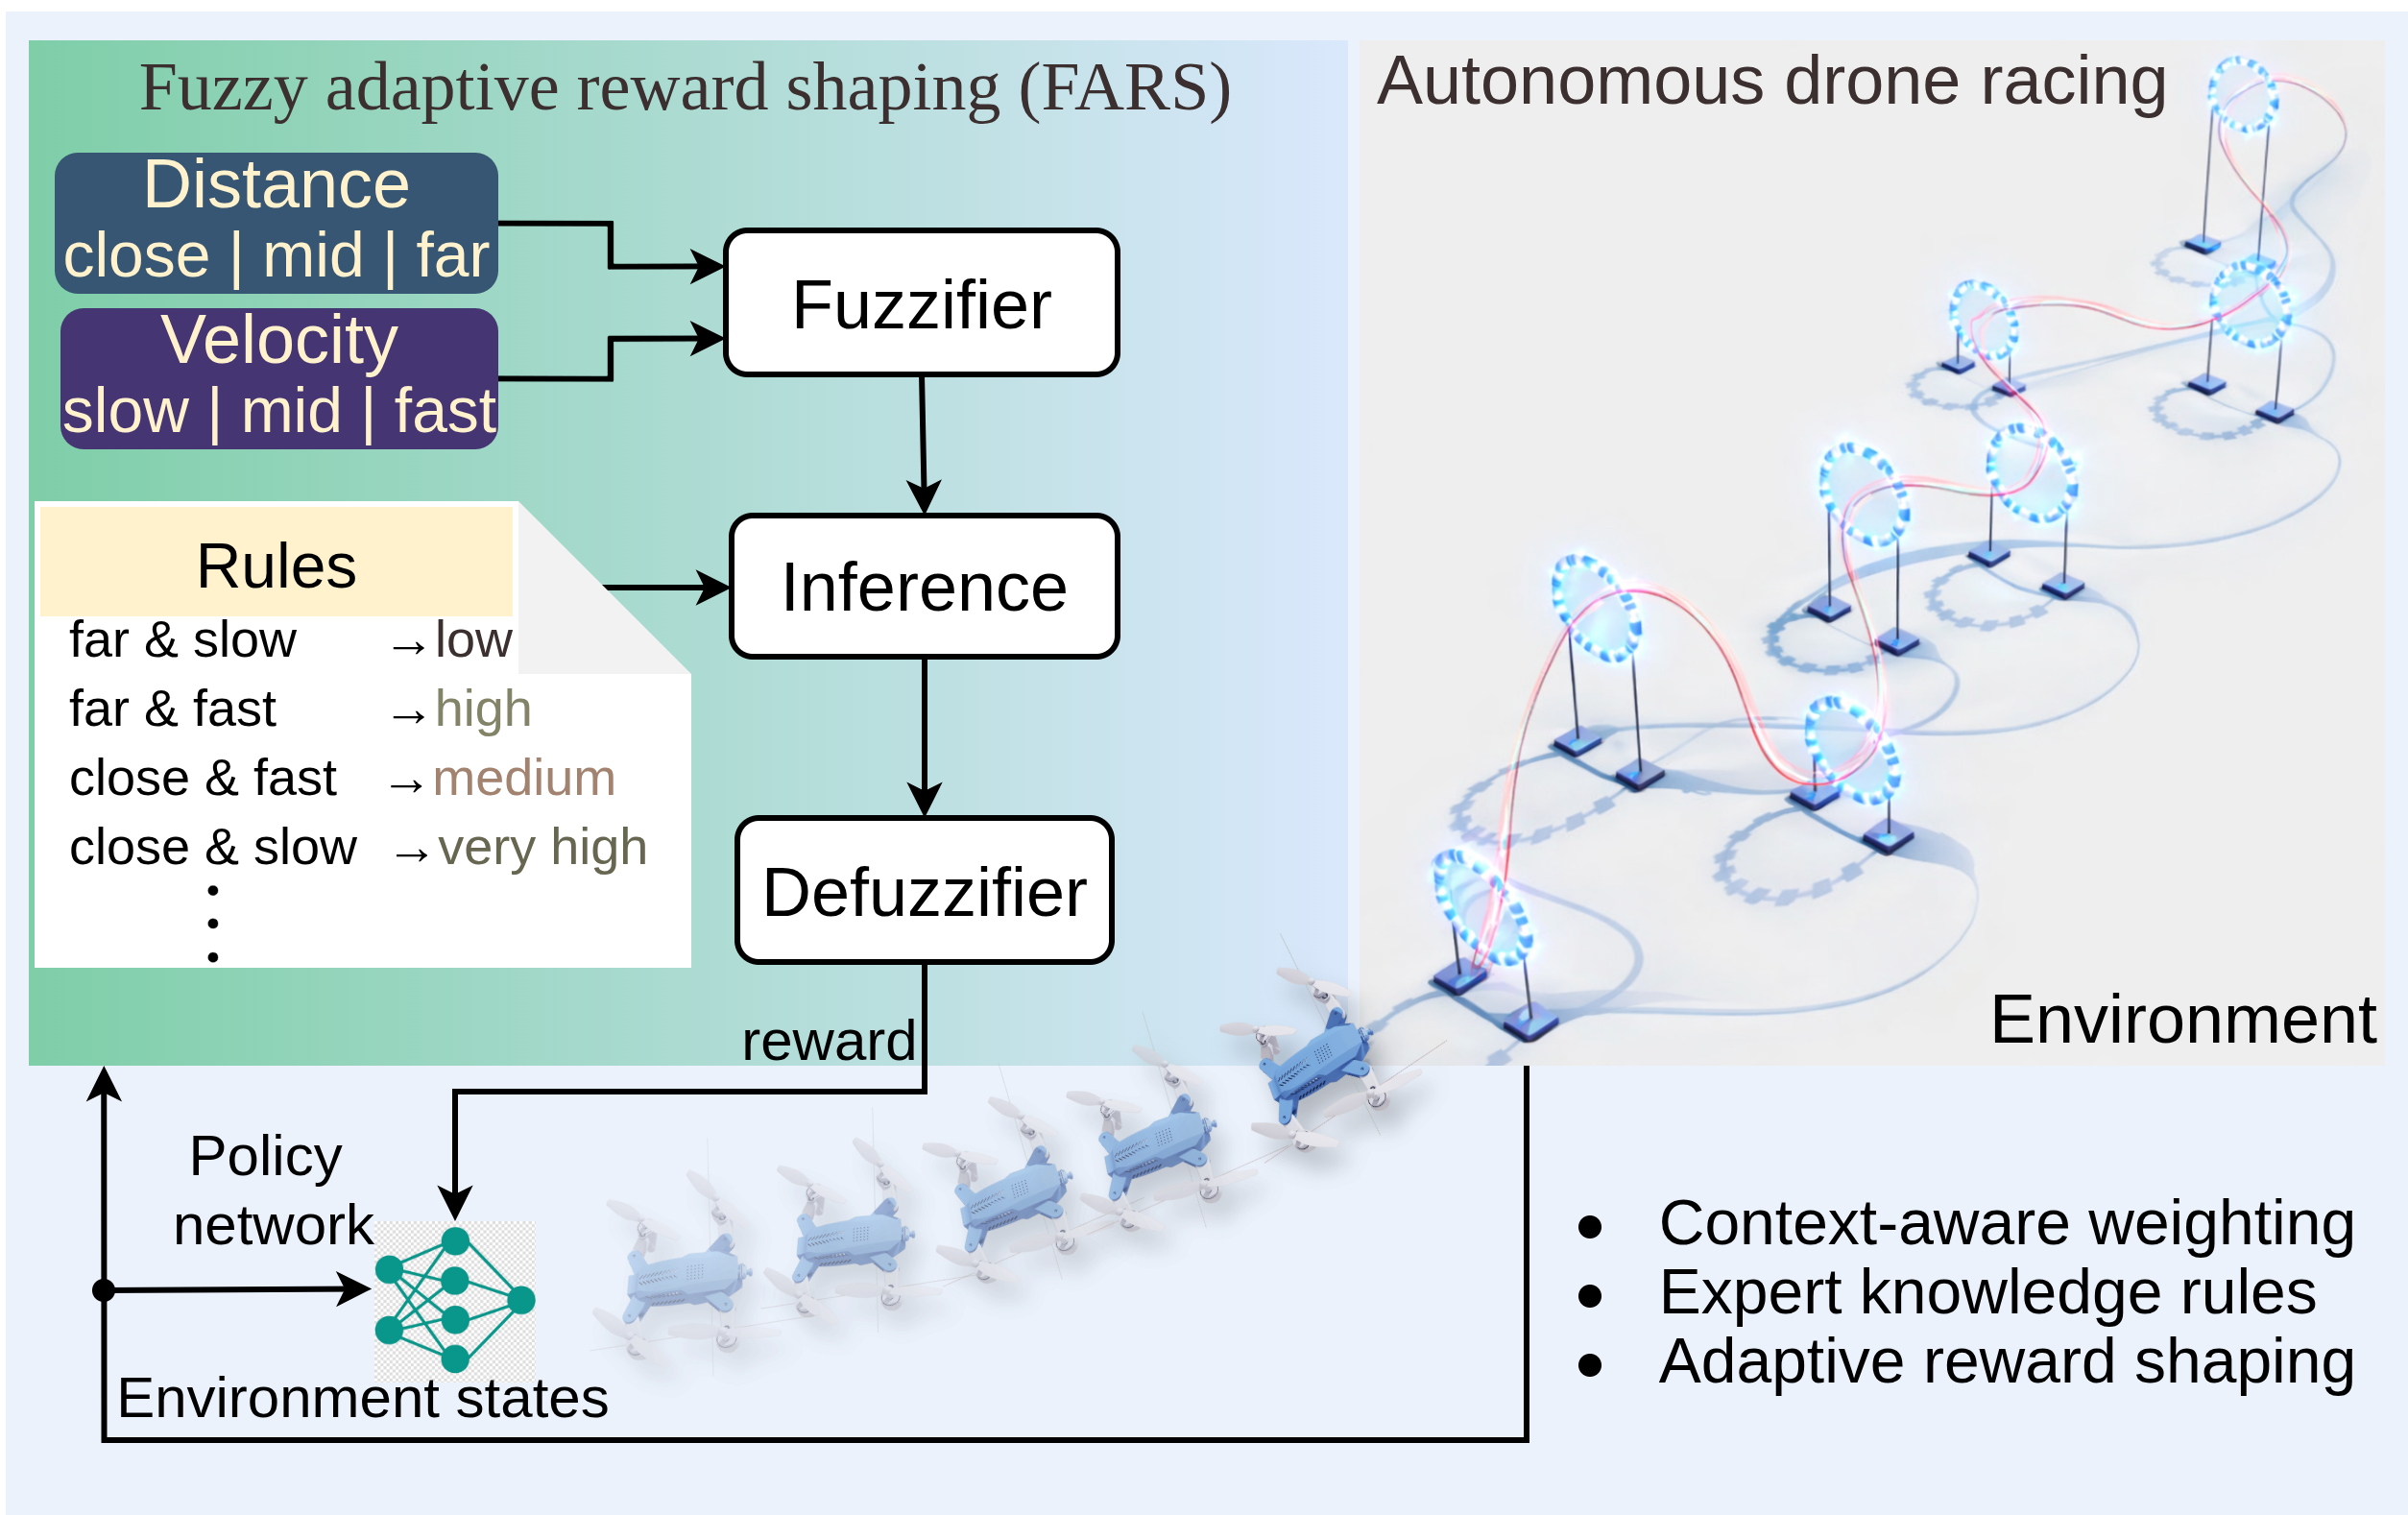
Fuzzy Logic Theory-based Adaptive Reward Shaping for Robust Reinforcement Learning (FARS)
IEEE World Congress on Computational Intelligence (WCCI), 2026
An interpretable fuzzy-logic reward shaping method that adaptively shapes velocity-distance rewards using human-like linguistic rules, demonstrated on autonomous drone racing in IsaacLab.
AIM '26
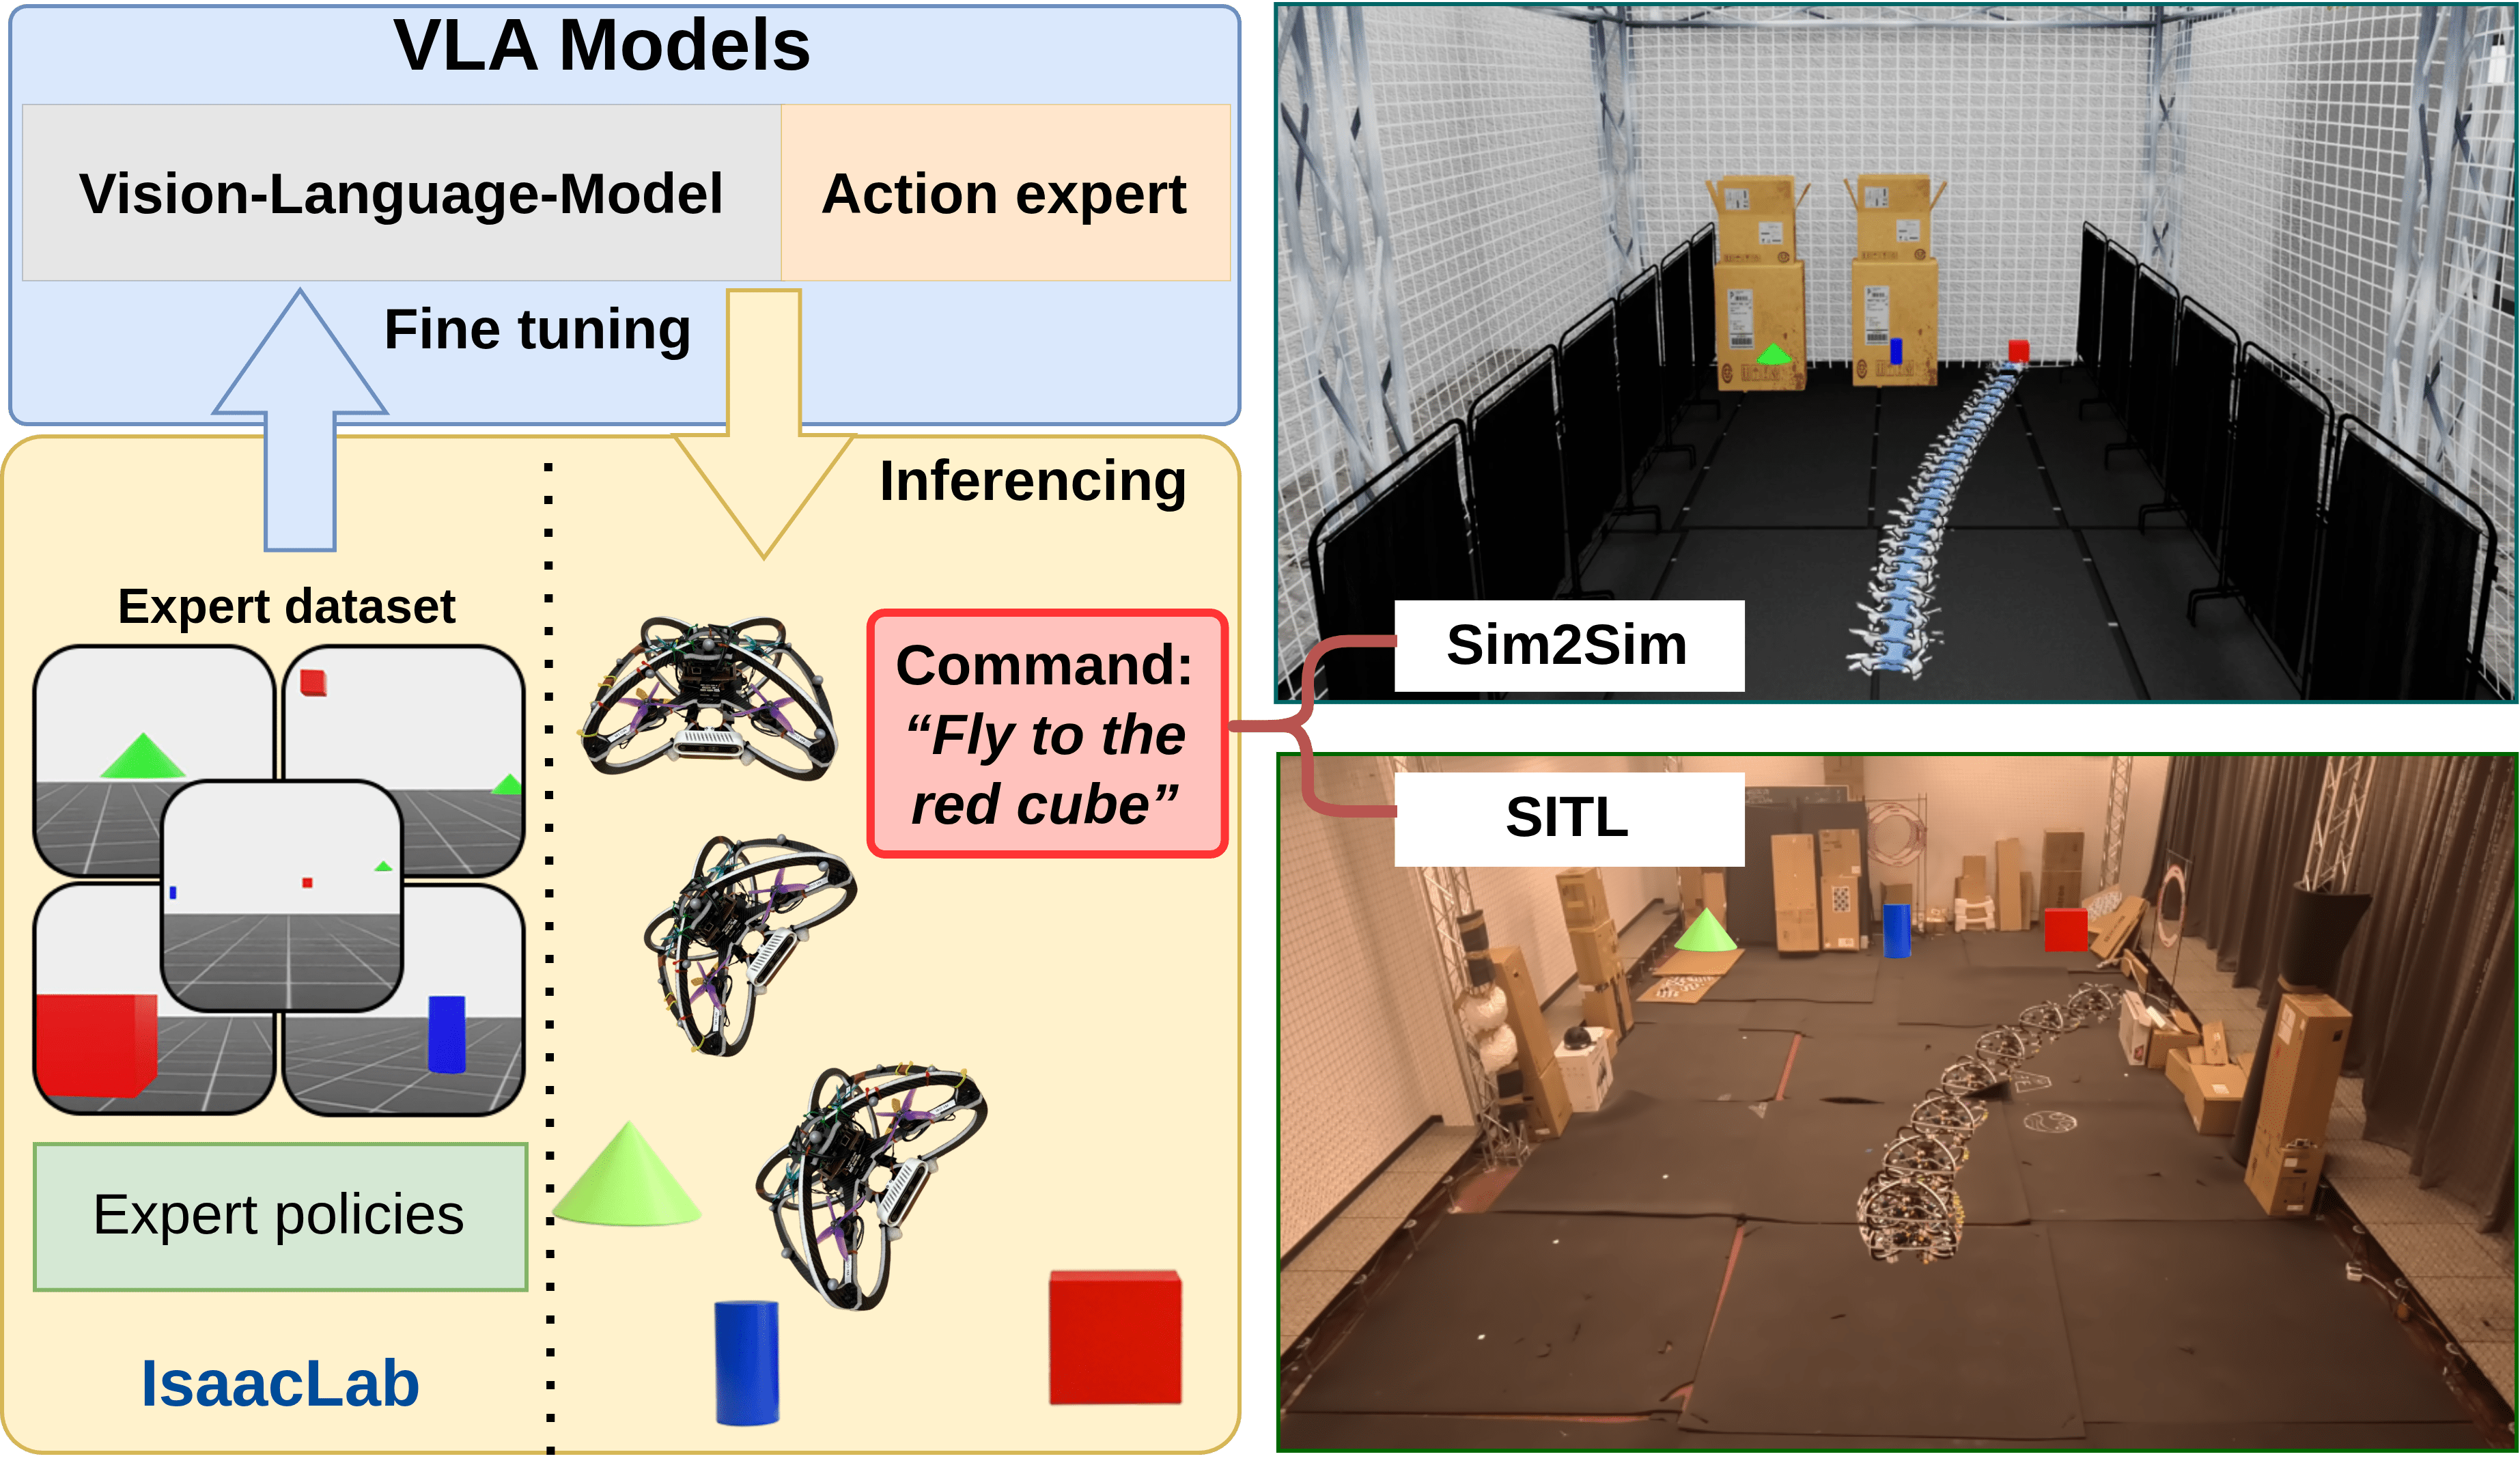
Exp2VLA: Enabling Vision–Language–Action for Drone Navigation from Expert Demonstrations
IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), 2026
A practical expert-distillation pipeline transferring RL and optimal control demonstrations into compact Vision-Language-Action (VLA) models for language-conditioned aerial drone navigation.
NeurIPS '24

Diffusion-based Curriculum Reinforcement Learning
Neural Information Processing Systems (NeurIPS), 2024
Generative CRL framework leveraging conditional diffusion models conditioned on Q-value feasibility and AIM reward proximity to synthesize optimal curriculum goals.
ICRA '24

Contact Energy Based Hindsight Experience Prioritization
IEEE International Conference on Robotics and Automation (ICRA), Yokohama, 2024
Prioritizes replay buffers using contact energy and tactile forces measured at the robot gripper, significantly expediting robotic manipulation policy learning.
ISA Trans '24

Toward Coordinated Planning and Hierarchical Optimization Control for Highly Redundant Mobile Manipulator
ISA Transactions (Elsevier), 2024
A coordinated motion planning and hierarchical optimization control framework for high-degree-of-freedom redundant mobile manipulators in constrained spaces.
IEEE Access '24

Curriculum Learning for Robot Manipulation Tasks with Sparse Reward Through Environment Shifts
IEEE Access, 2024
Proposes an environment-shifting curriculum learning paradigm that shifts physical parameters progressively to tackle sparse reward manipulation challenges.
GECCO '24
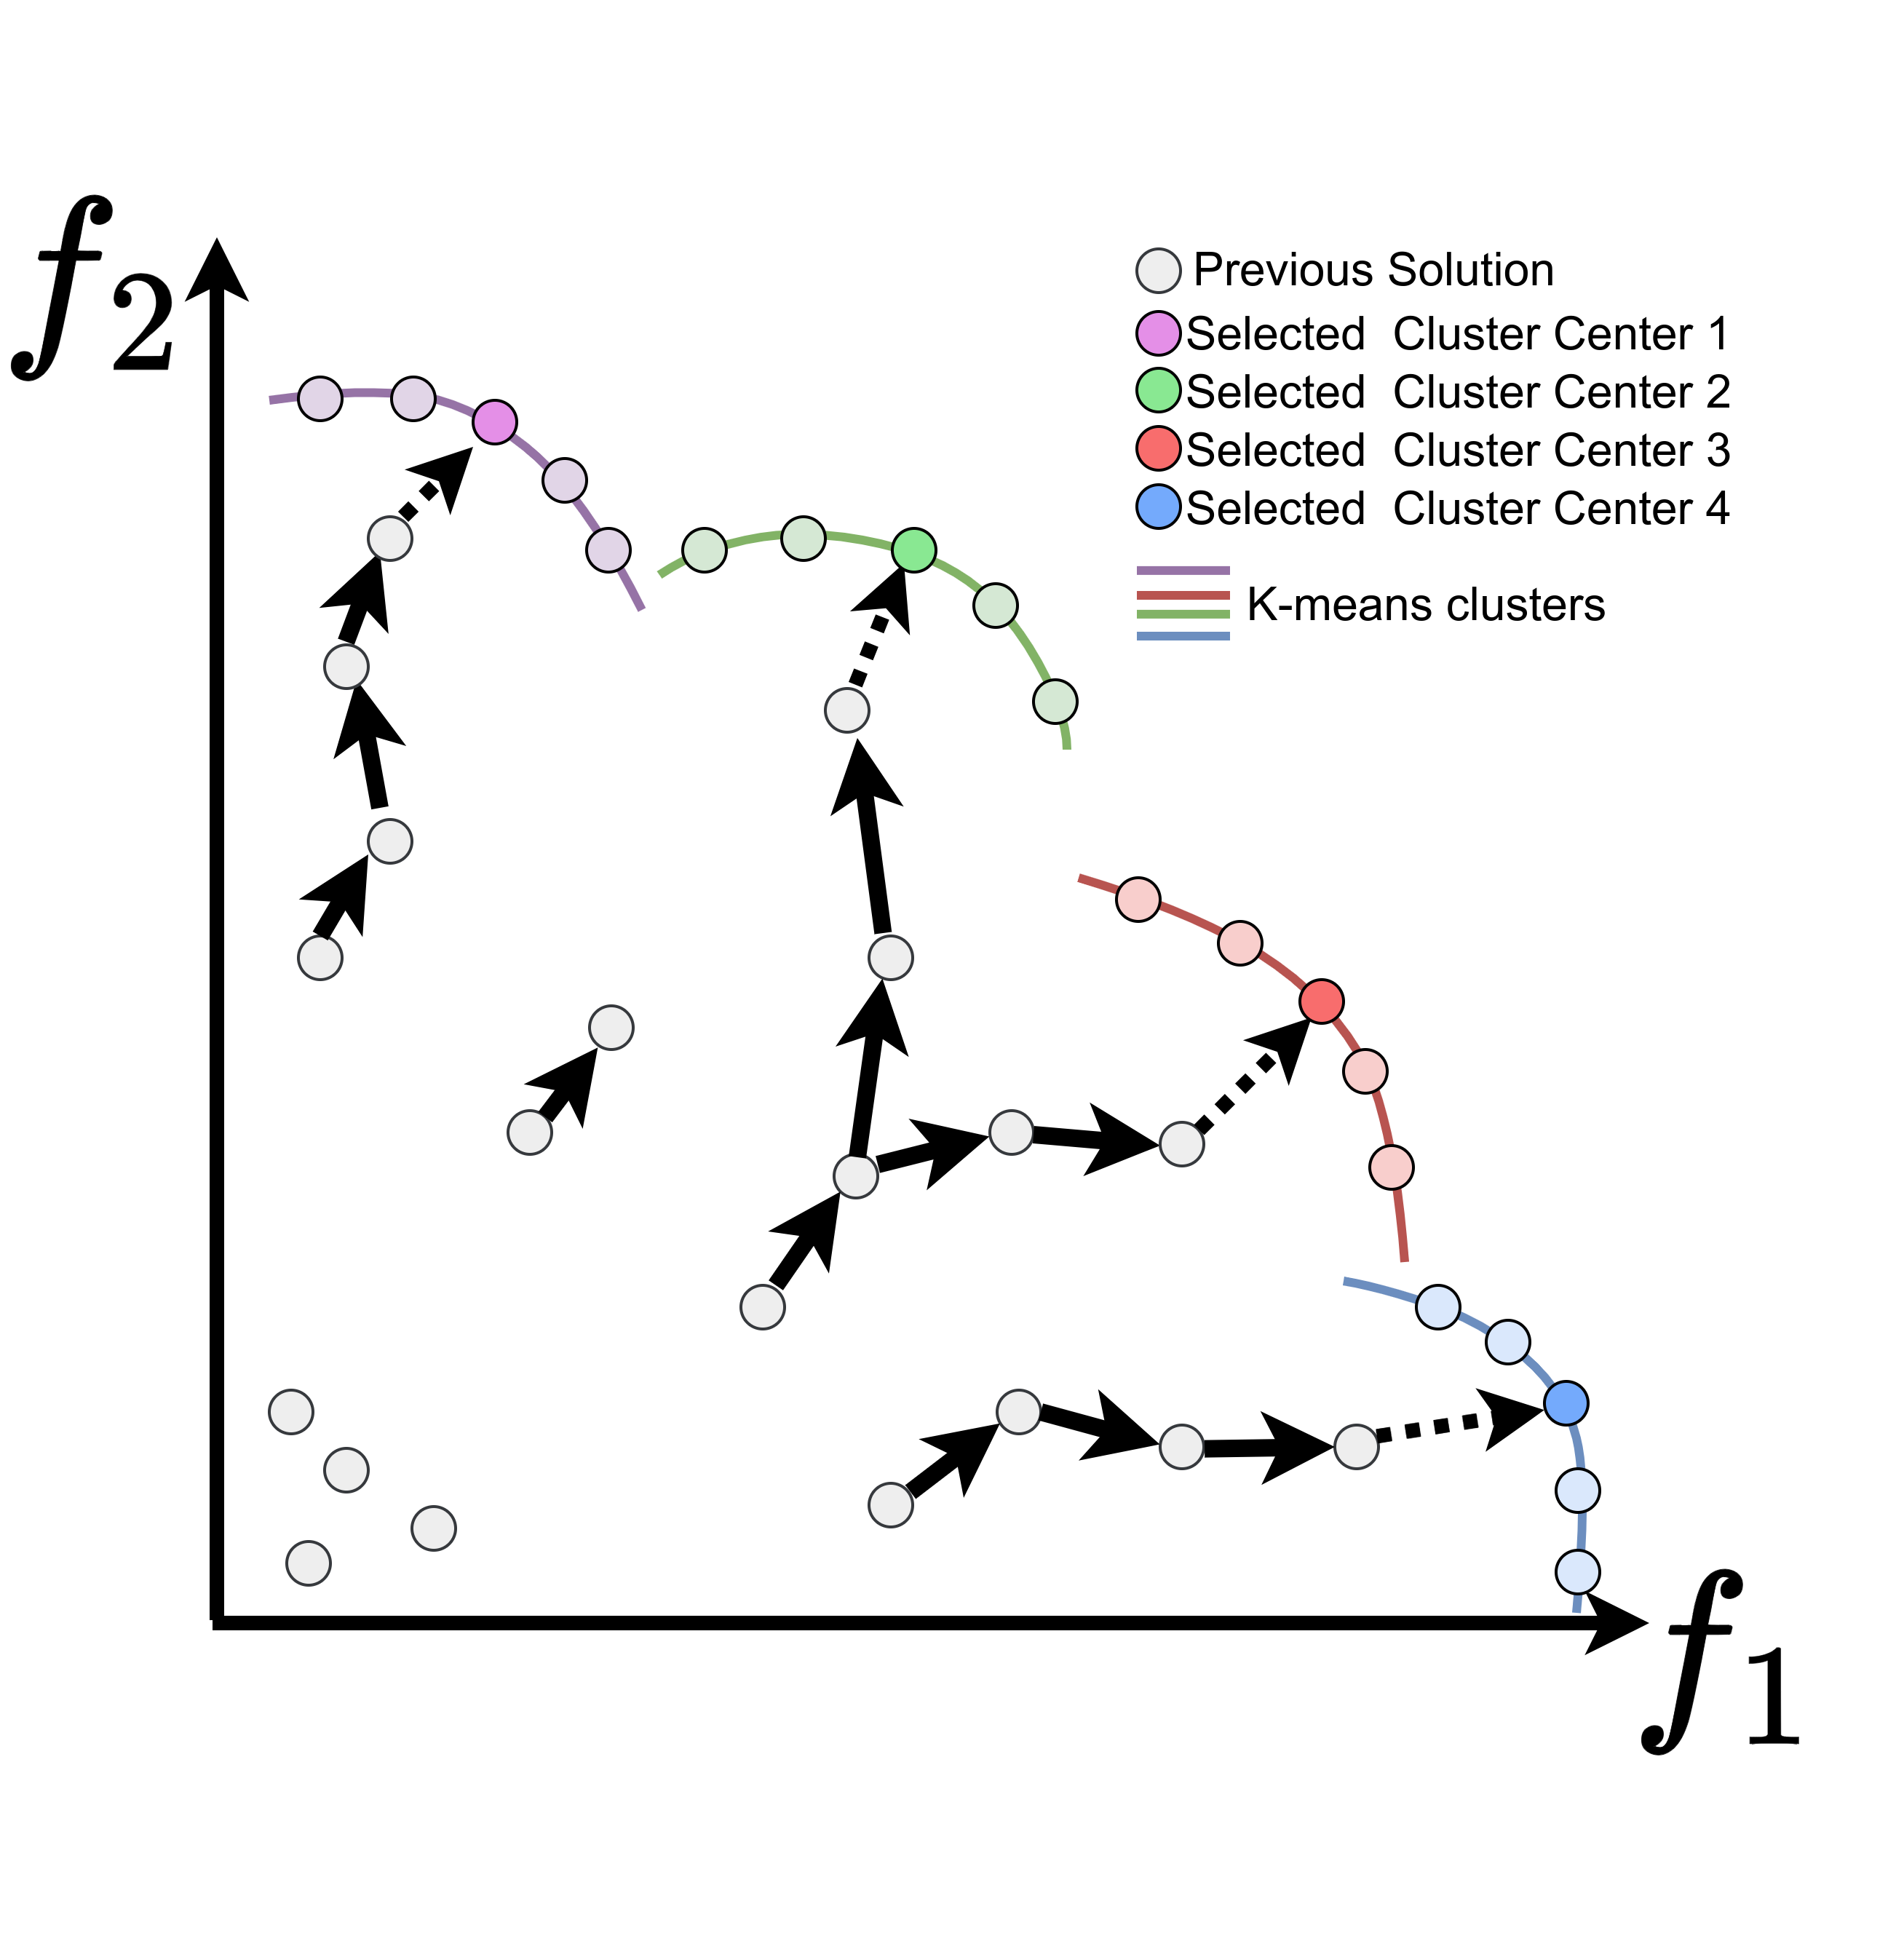
Multi-Objective Evolutionary Hindsight Experience Replay for Robot Manipulation Tasks
Genetic and Evolutionary Computation Conference (GECCO), Melbourne, 2024
Combines multi-objective evolutionary search (NSGA-II) with hindsight experience replay to optimize value prediction, goal-proximity potential, and Wasserstein distance under obstacle constraints.
EuroGP '24
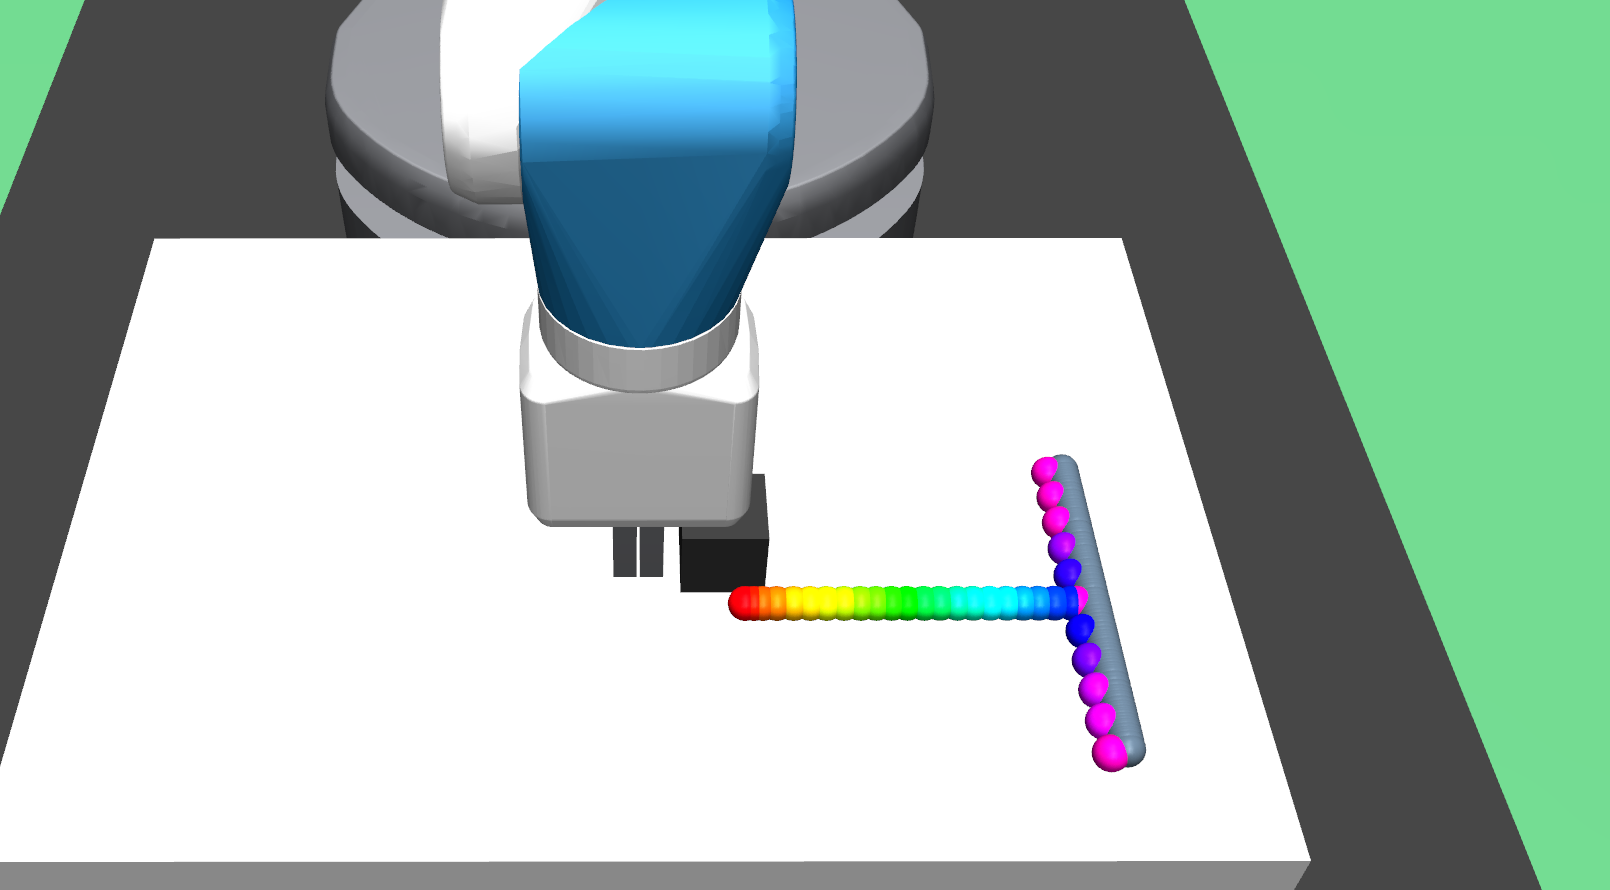
Hindsight Experience Replay with Evolutionary Decision Trees for Curriculum Goal Generation
EvoApplications / EuroGP (Springer LNCS Vol. 14634), 2024
Evolves interpretable binary decision trees via Grammatical Evolution and continuously refines waypoints using critic Q-value feedback for sparse-reward manipulation.
GECCO '22

Exploration of Unknown Environments via Evolution of Behavioral and Morphological Properties of Miniaturized Sensory Agents
ACM Genetic and Evolutionary Computation Conference (GECCO), Boston, 2022
Co-evolves morphological and behavioral traits of miniaturized swarm sensory agents exploring uncharted environments.
Adding a New Publication Project Site?
Use our pre-configured, responsive academic project template. Simply duplicate the template folder, plug in your paper title, abstract, demo videos, and BibTeX!
View Project Page Template