Publications

Selected peer-reviewed papers, journals, and project sites.

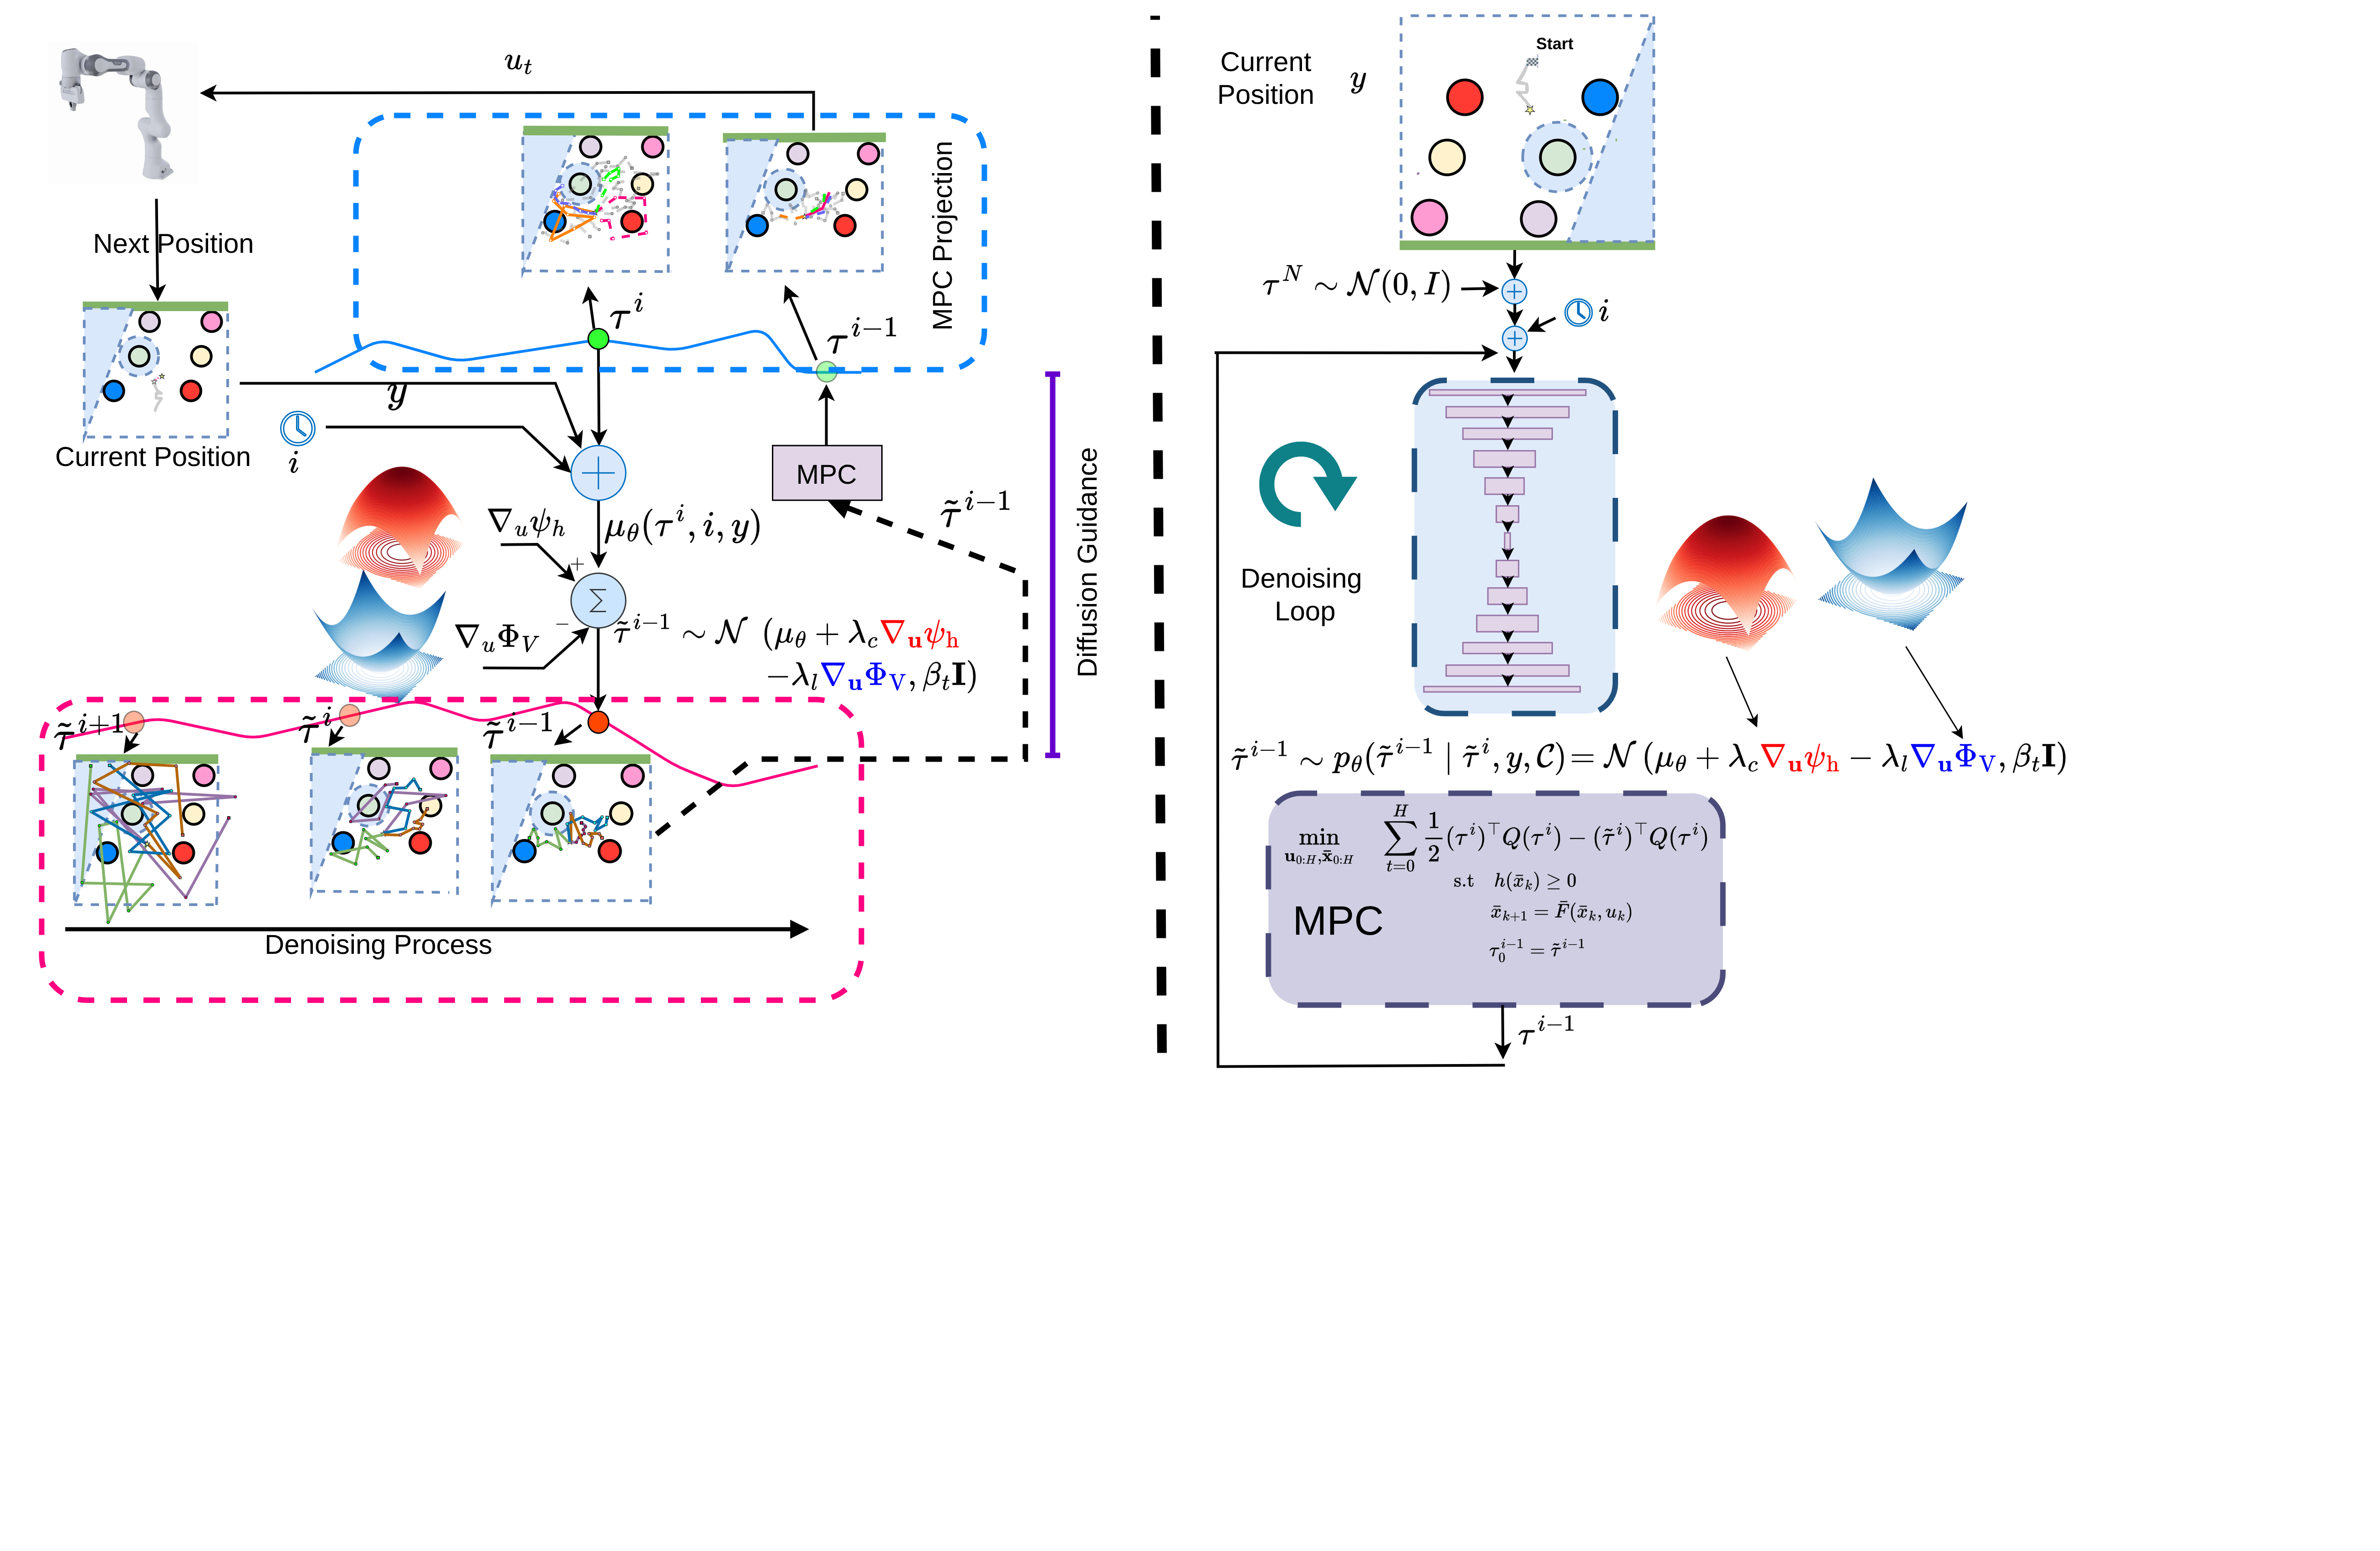
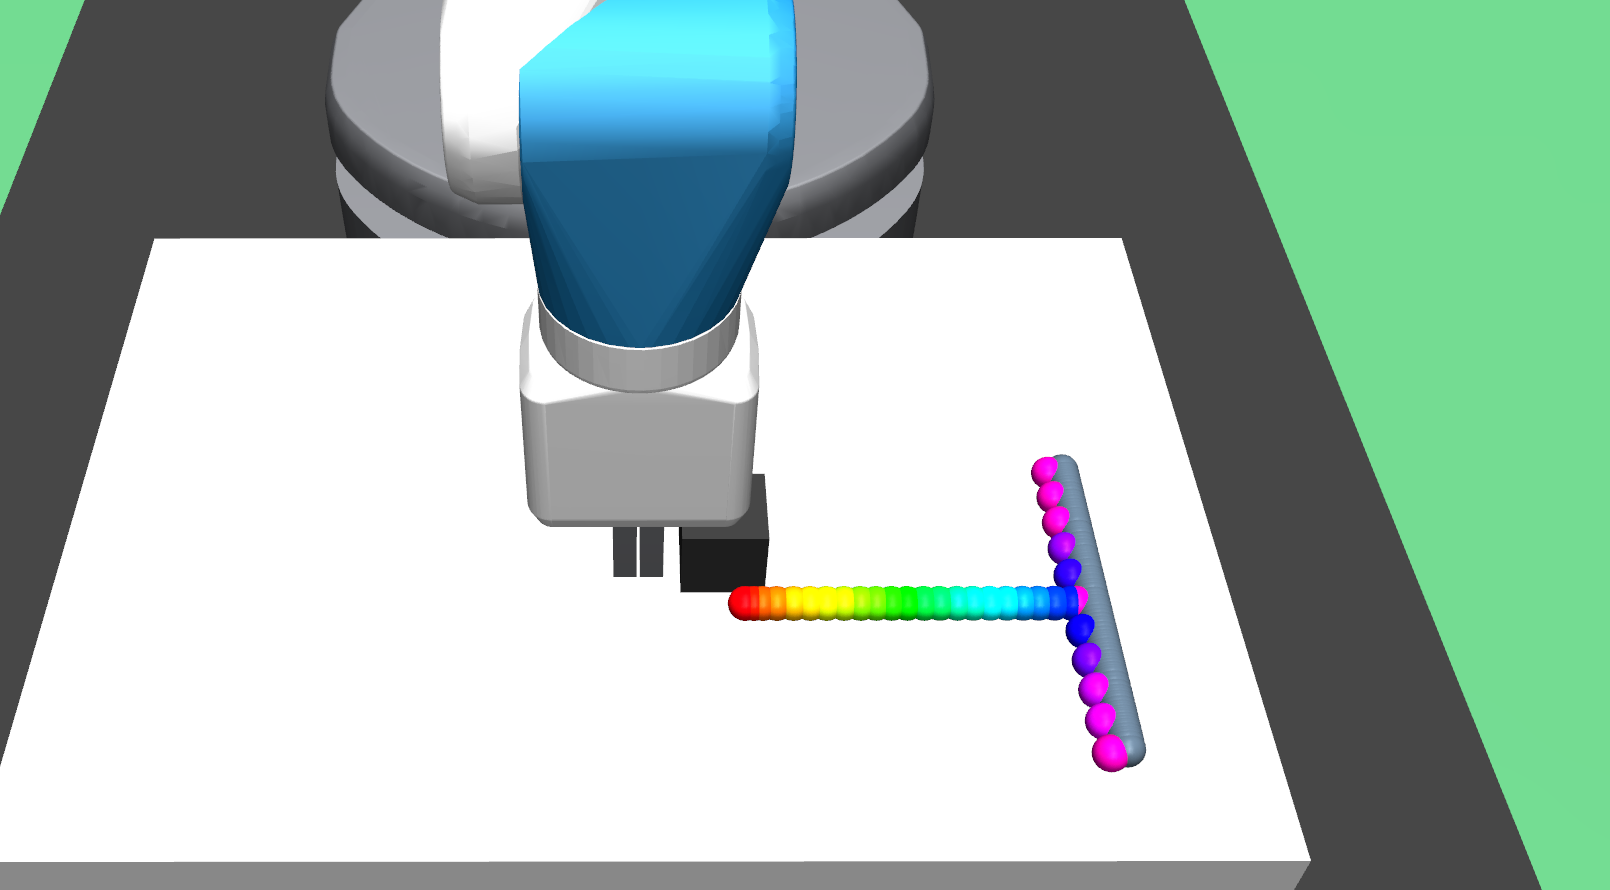
IROS '26 D-SafeMPC Architecture

D-SafeMPC: Diffusion-Driven Safe Model Predictive Control with Discrete-Time Control Barrier Functions

Erdi Sayar, Ersin Daş, Joel W. Burdick, Alois Knoll, Erdal Kayacan
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Pittsburgh, 2026
A unified framework coupling discrete-time CBF and CLF-guided reverse diffusion with iterative-projection MPC for safe robot trajectory generation under dynamic constraints, validated on a physical 7-DOF Franka manipulator.
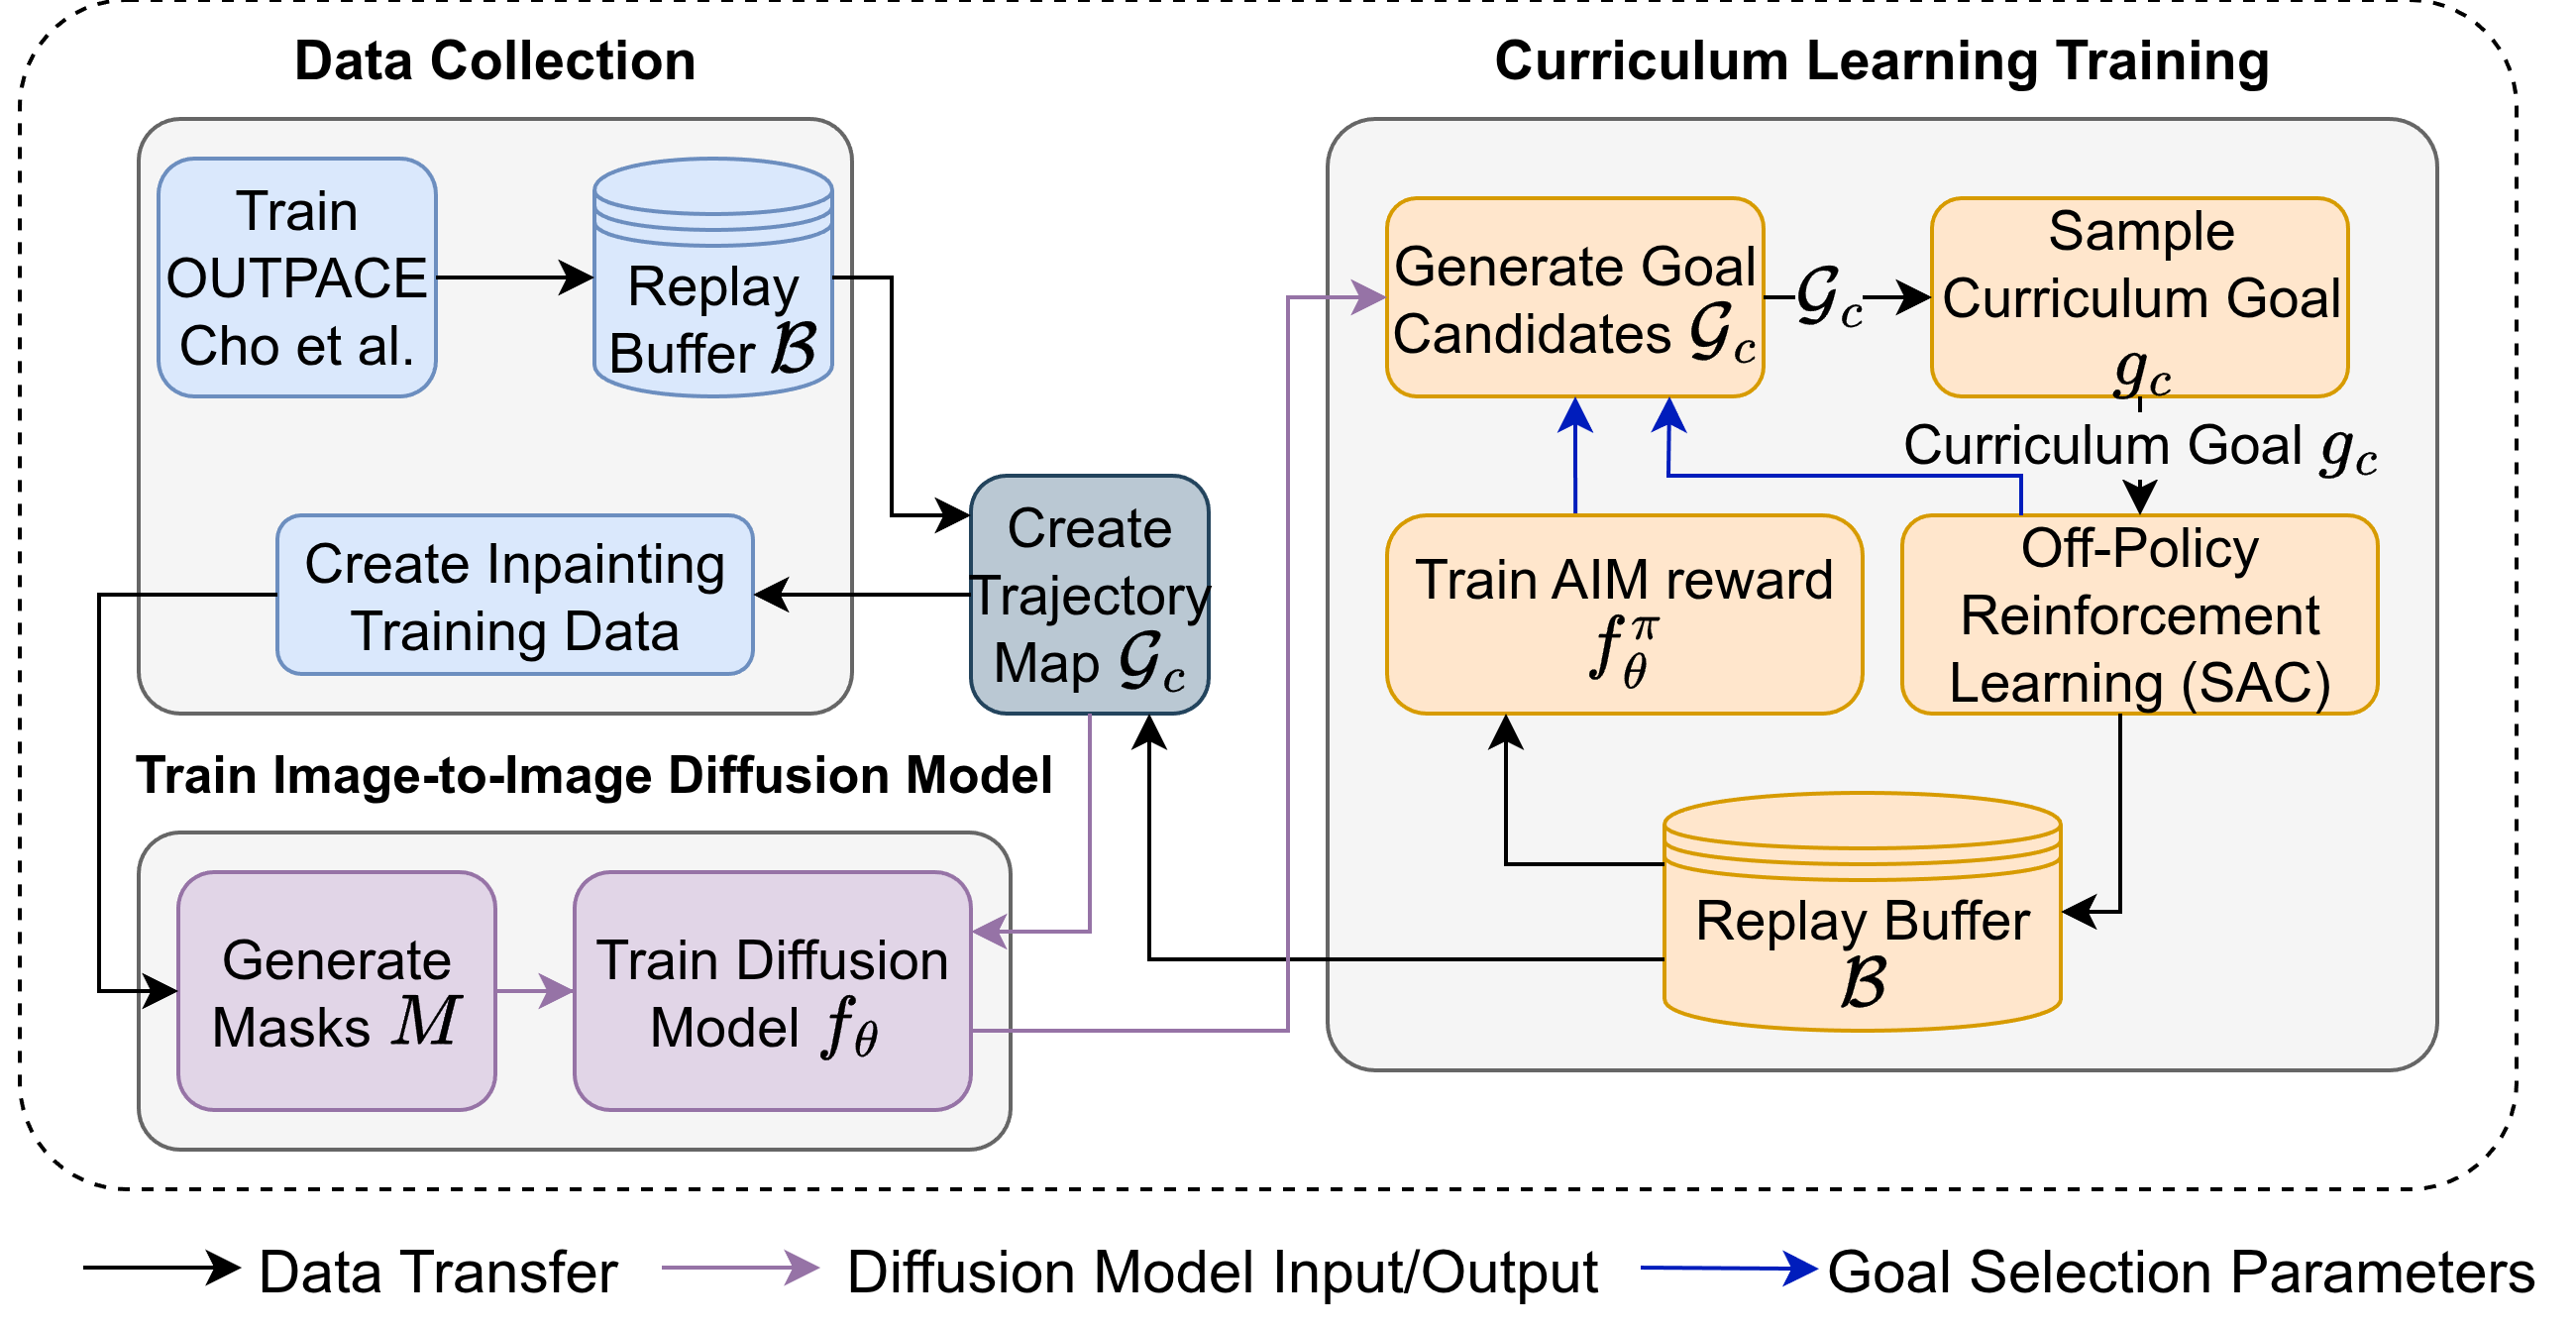
WCCI '26 PIDCRL Architecture

Palette Inpainting Diffusion Curriculum Reinforcement Learning (PIDCRL)

Faruk Oruç, Erdi Sayar, Giovanni Iacca, Alois Knoll, Erdal Kayacan
IEEE World Congress on Computational Intelligence (WCCI), 2026
A diffusion-based CRL framework that adapts mask-conditional image inpainting on trajectory heatmaps to automatically generate achievable, progressively challenging curriculum goals.
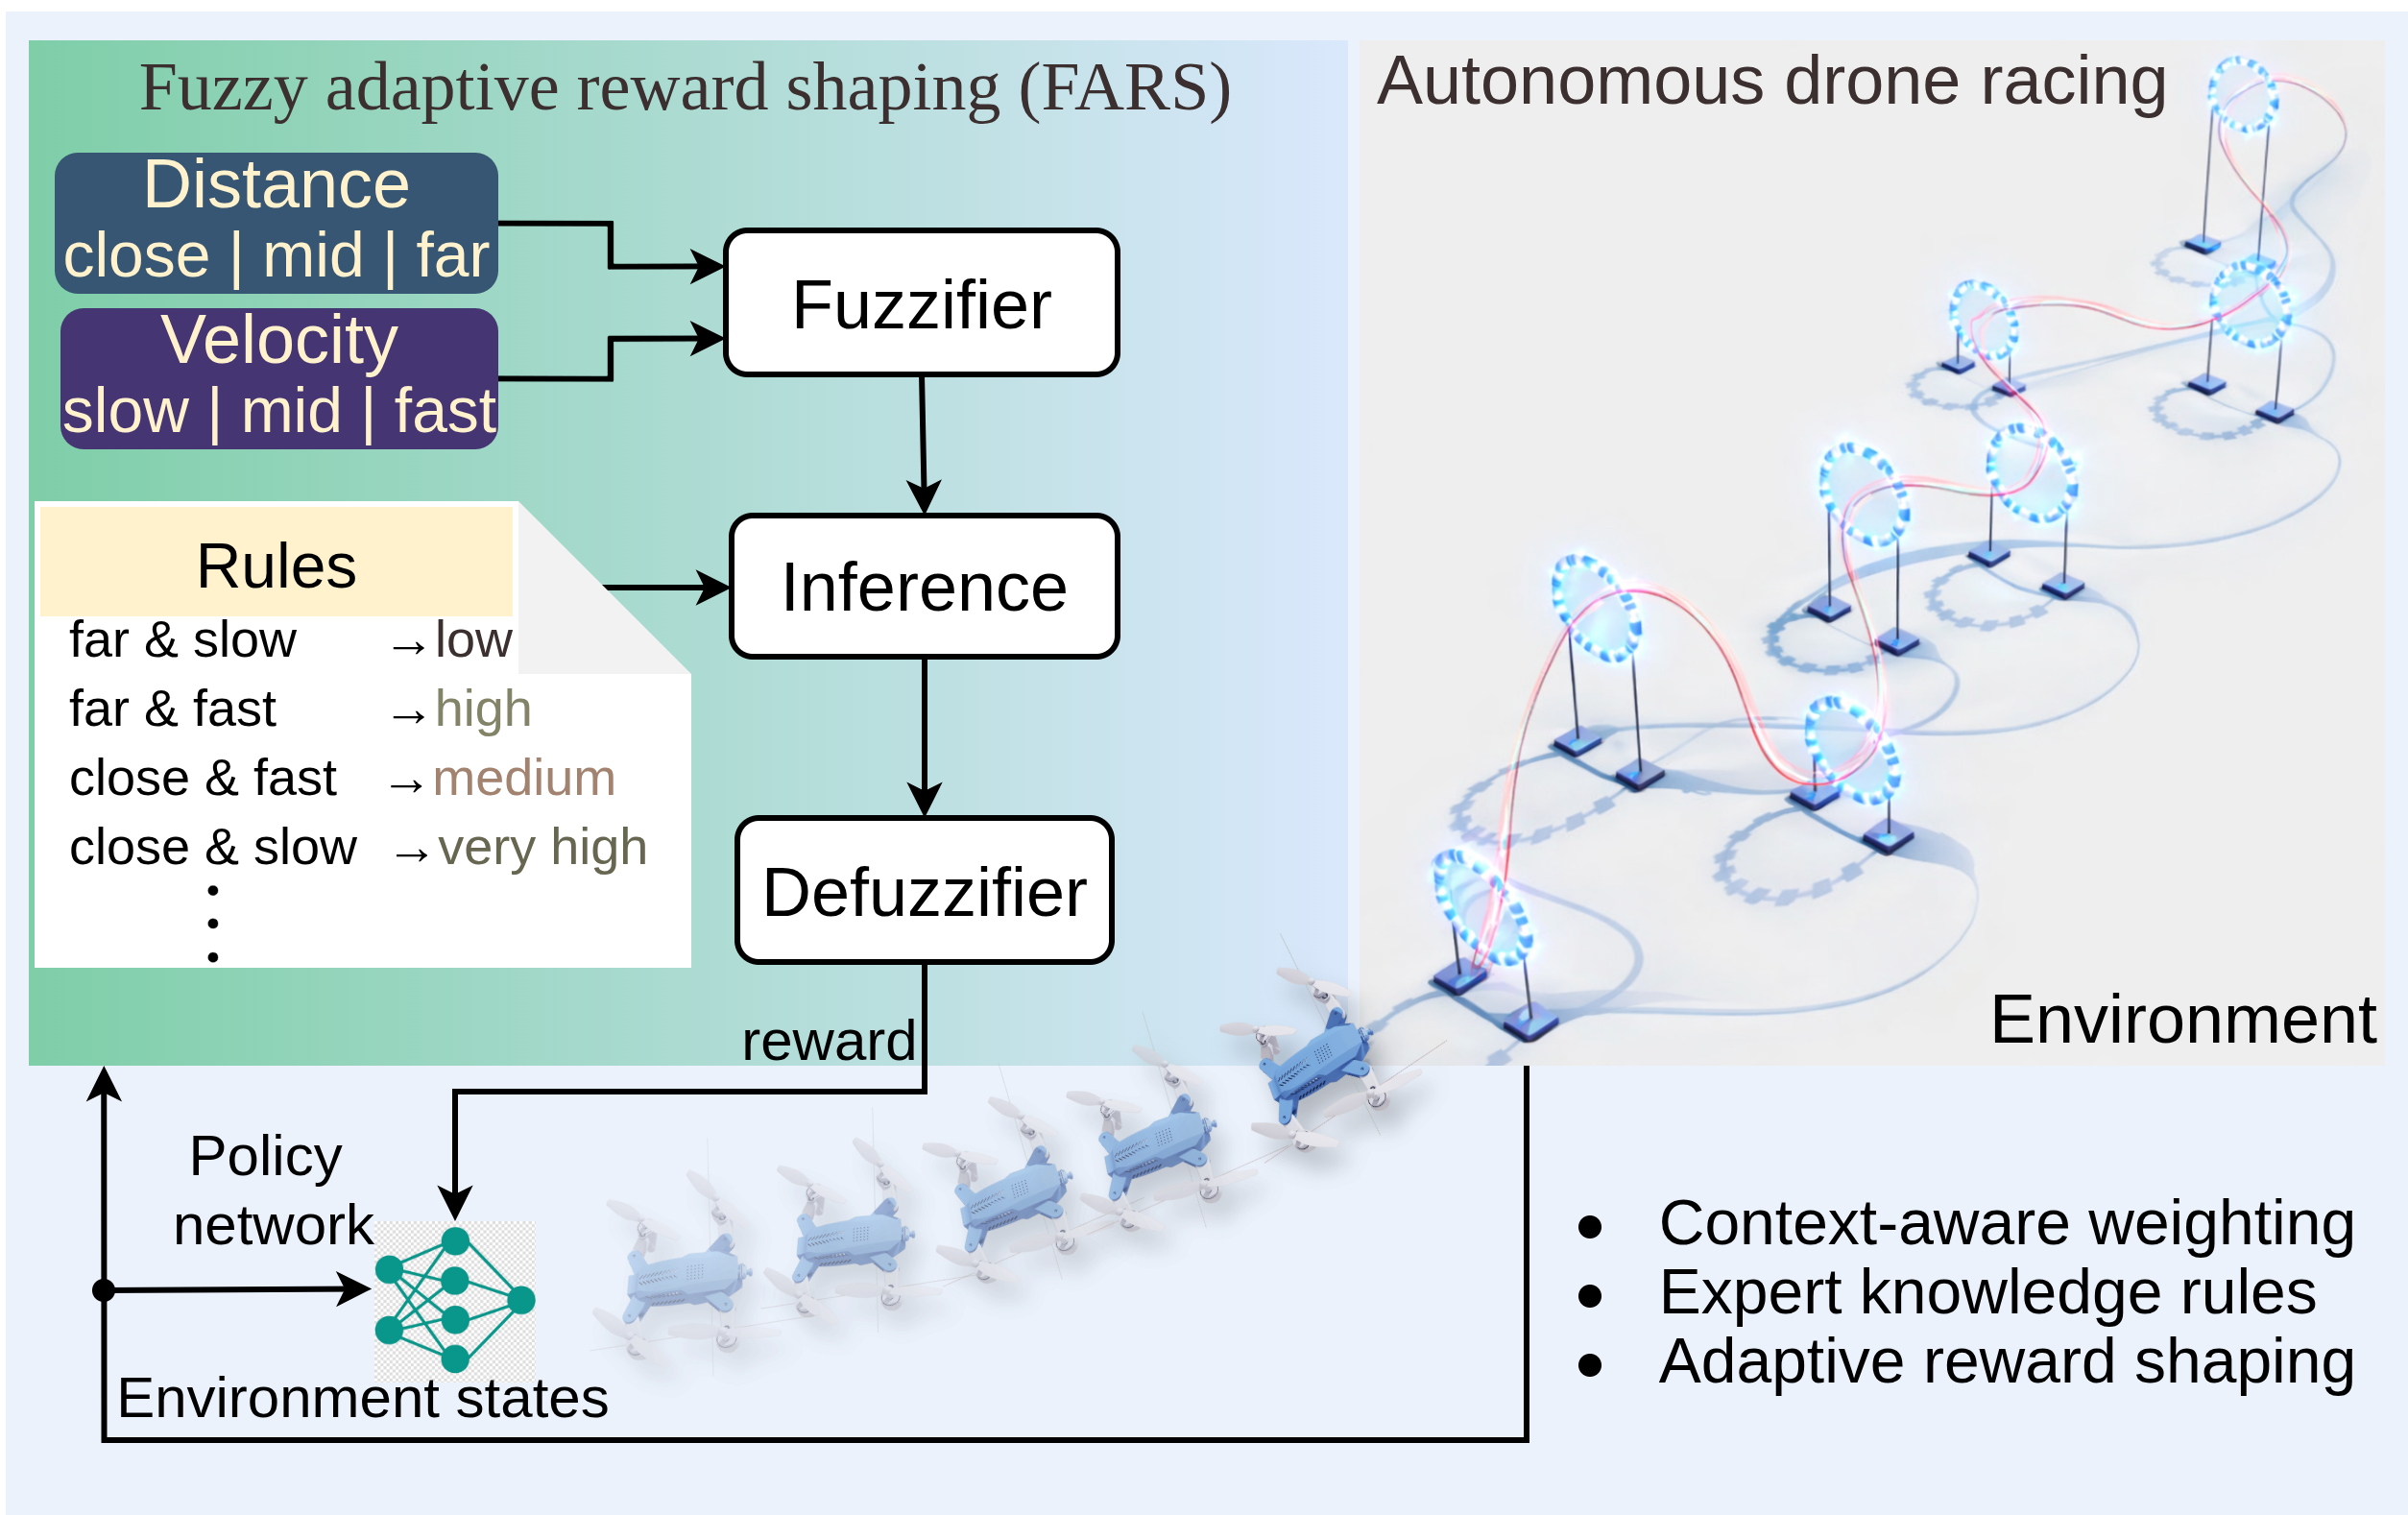
WCCI '26 FARS Method Overview

Fuzzy Logic Theory-based Adaptive Reward Shaping for Robust Reinforcement Learning (FARS)

Hürkan Şahin, Van Huyen Dang, Erdi Sayar, Alper Yegenoglu, Erdal Kayacan
IEEE World Congress on Computational Intelligence (WCCI), 2026
An interpretable fuzzy-logic reward shaping method that adaptively shapes velocity-distance rewards using human-like linguistic rules, demonstrated on autonomous drone racing in IsaacLab.
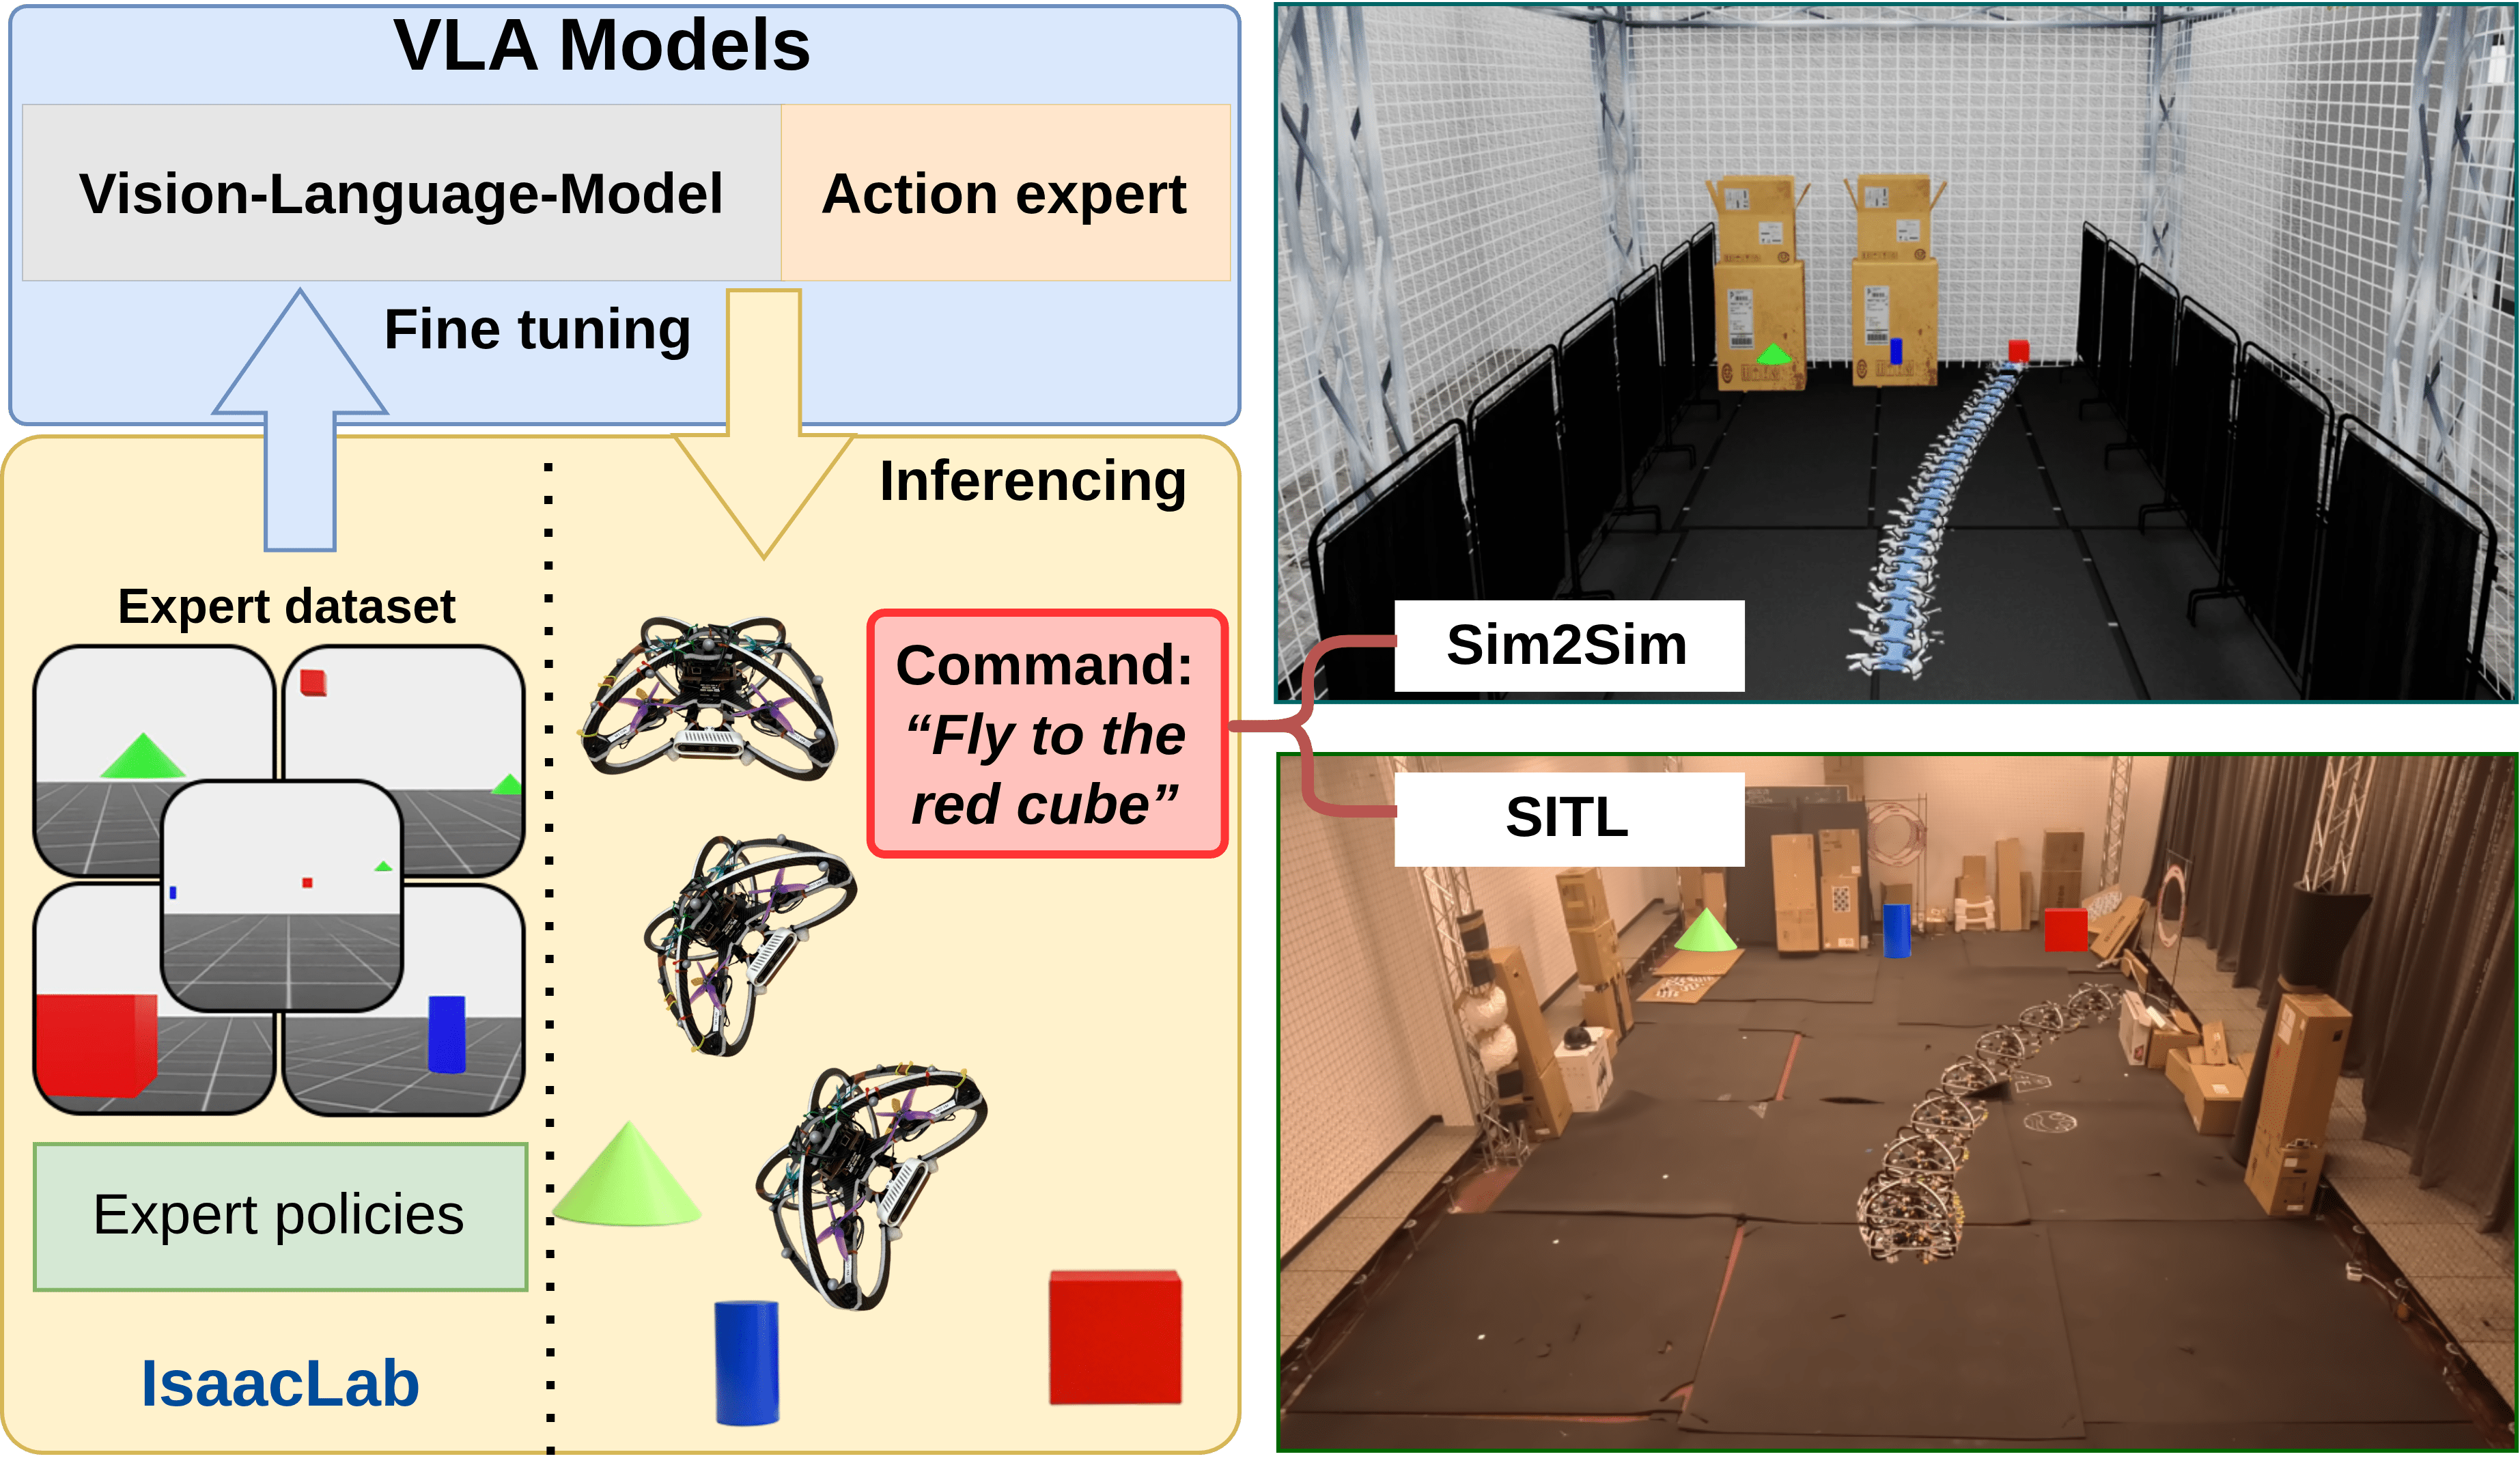
AIM '26 Exp2VLA Overview

Exp2VLA: Enabling Vision–Language–Action for Drone Navigation from Expert Demonstrations

Van Huyen Dang, Kabilesh Rajendran, Erdi Sayar, Erdal Kayacan
IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), 2026
A practical expert-distillation pipeline transferring RL and optimal control demonstrations into compact Vision-Language-Action (VLA) models for language-conditioned aerial drone navigation.
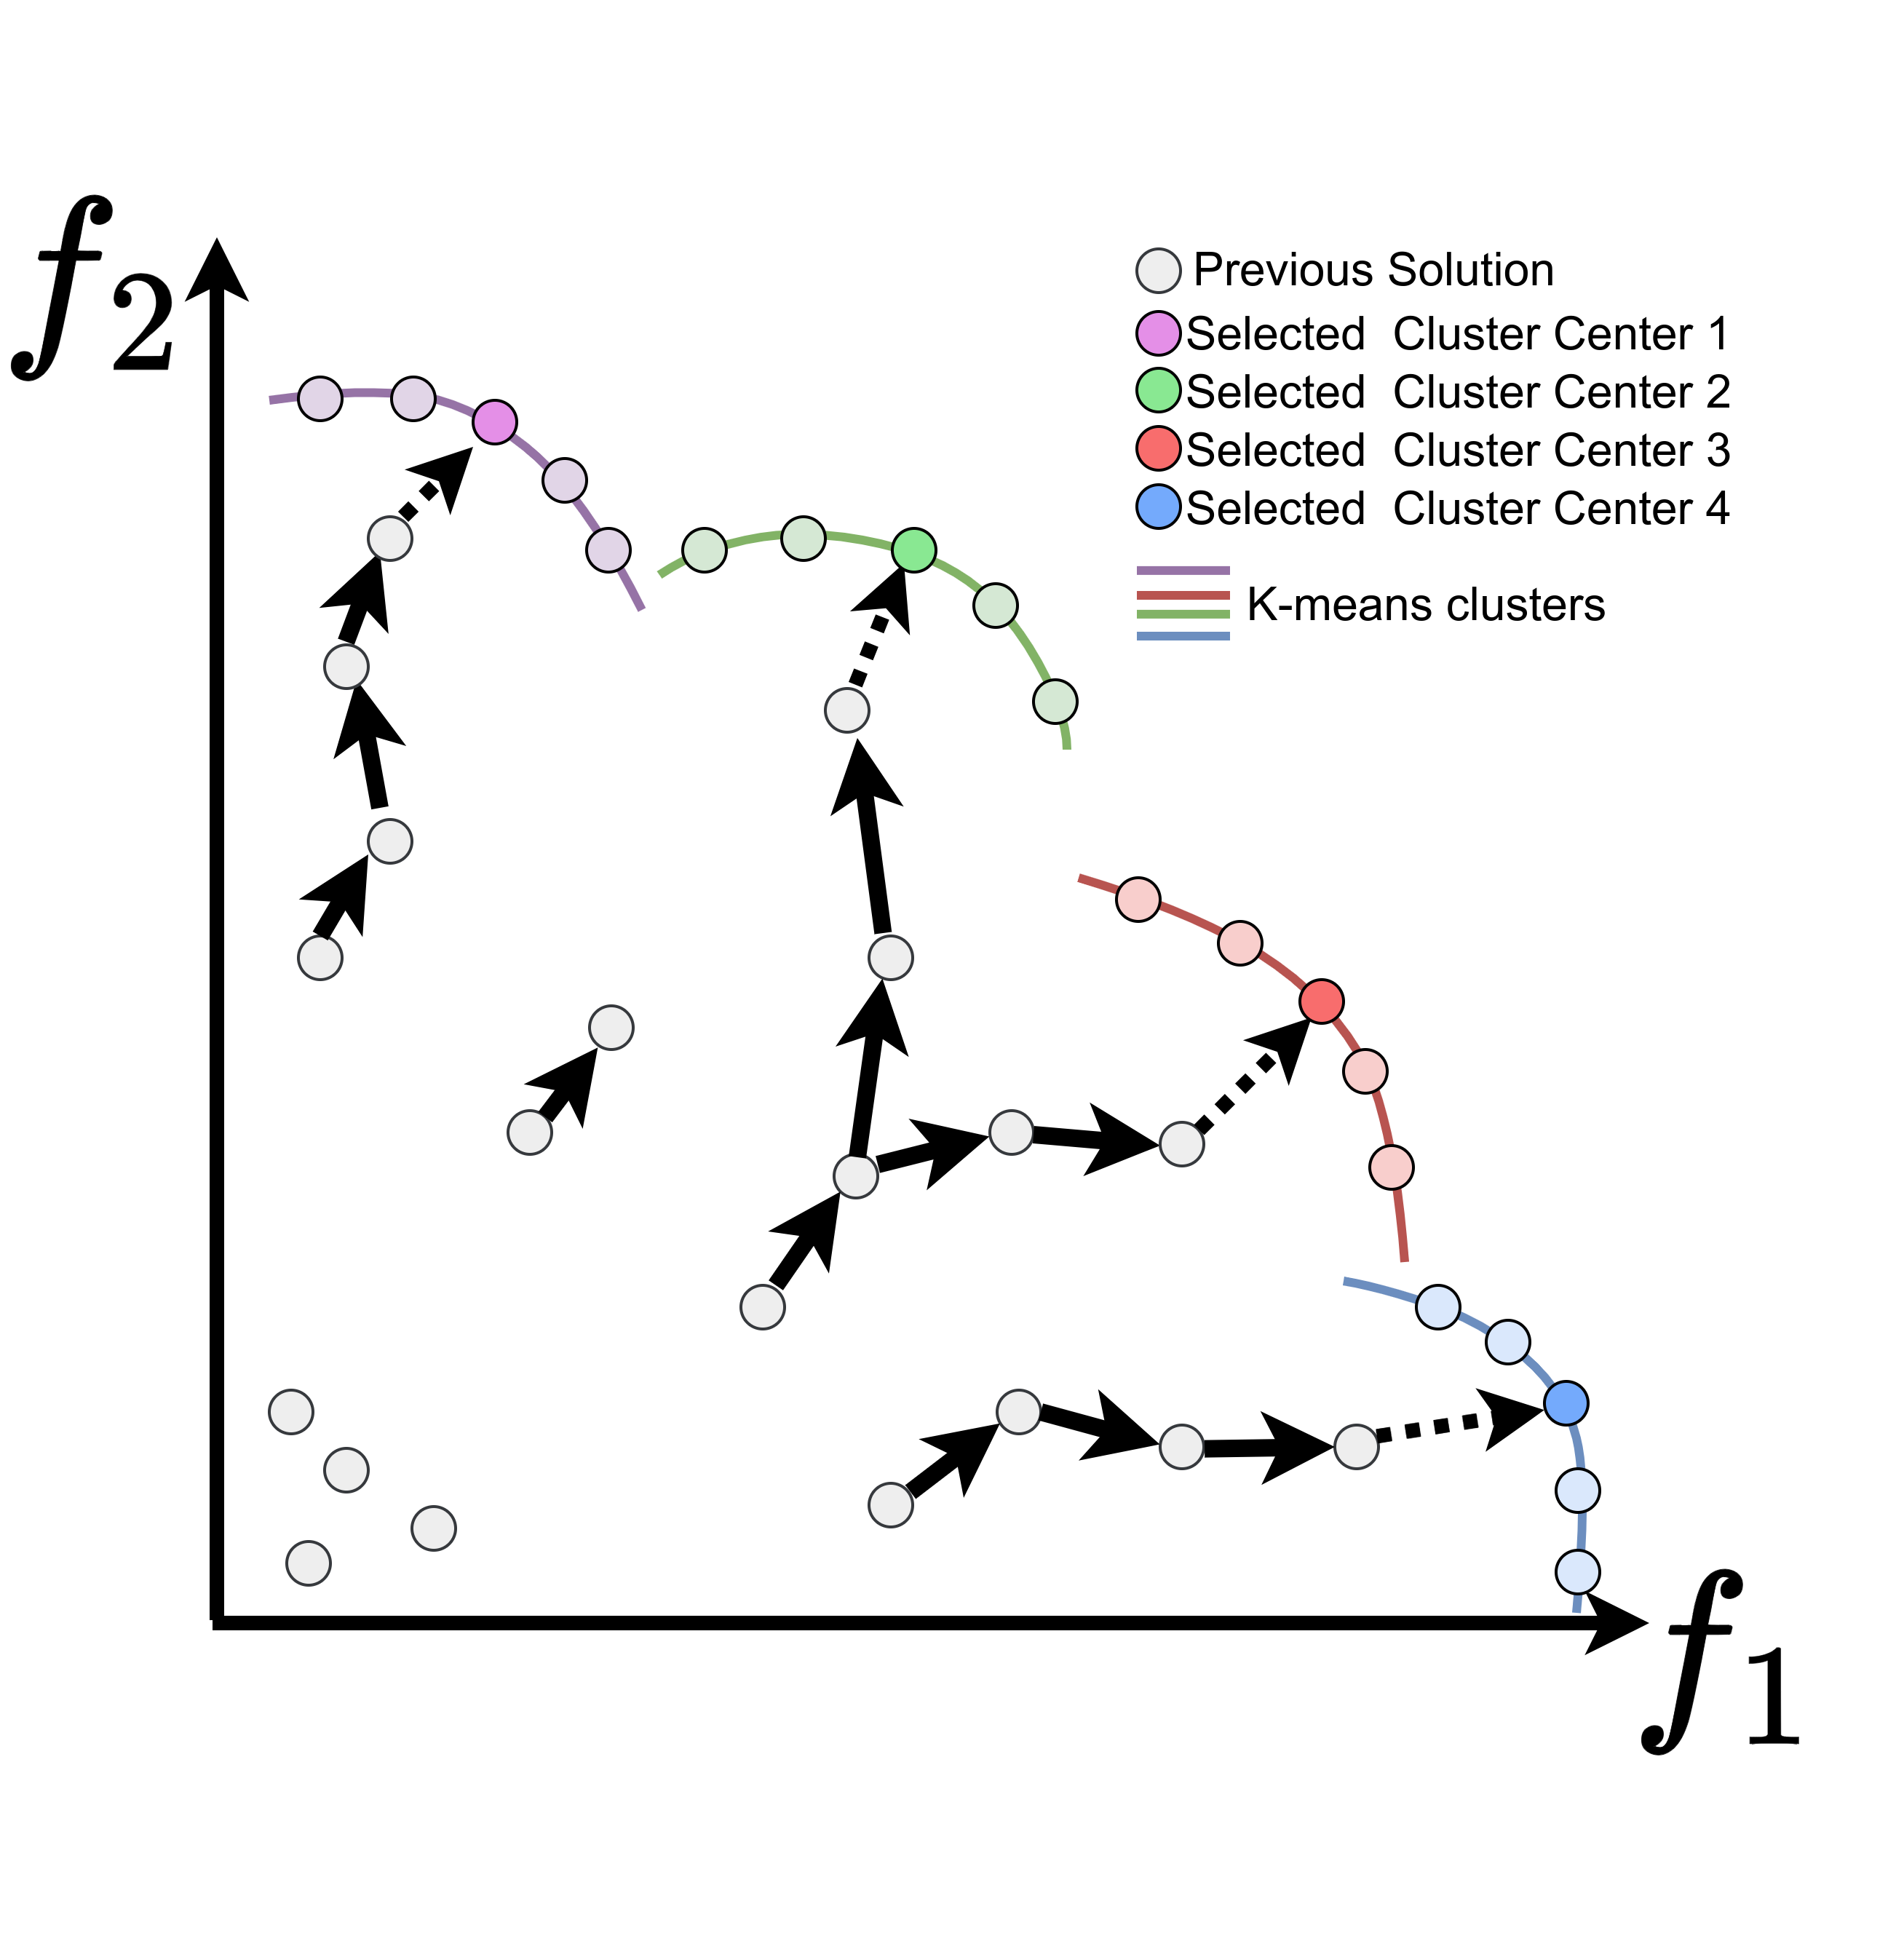
NeurIPS '24 Diffusion-based Curriculum RL

Diffusion-based Curriculum Reinforcement Learning

Erdi Sayar, Giovanni Iacca, Ozgur S. Oguz, Alois Knoll
Neural Information Processing Systems (NeurIPS), 2024
Generative CRL framework leveraging conditional diffusion models conditioned on Q-value feasibility and AIM reward proximity to synthesize optimal curriculum goals.
ICRA '24 Contact Energy Based HER

Contact Energy Based Hindsight Experience Prioritization

Erdi Sayar, Zhenshan Bing, Carlo D'Eramo, Ozgur S. Oguz, Alois Knoll
IEEE International Conference on Robotics and Automation (ICRA), Yokohama, 2024
Prioritizes replay buffer transitions using tactile contact forces and mechanical work, accelerating policy convergence on complex multi-goal manipulation tasks.
ISA Trans '24 Mobile Manipulator Coordinated Planning

Toward Coordinated Planning and Hierarchical Optimization Control for Highly Redundant Mobile Manipulator

Erdi Sayar, Xiang Gao, Yingbai Hu, Guang Chen, Alois Knoll
ISA Transactions (Elsevier), 2024
A hierarchical optimization and coordinated trajectory planning architecture for high-DOF mobile manipulators navigating cluttered obstacle environments.
IEEE Access '24 Curriculum Learning through Environment Shifts

Curriculum Learning for Robot Manipulation Tasks with Sparse Reward Through Environment Shifts

Erdi Sayar, Giovanni Iacca, Alois Knoll
IEEE Access, 2024
Environment-shifting curriculum mechanisms that systematically ease task physics during exploration to bypass sample complexity bottlenecks in sparse rewards.
GECCO '24 Multi-Objective Evolutionary HER

Multi-Objective Evolutionary Hindsight Experience Replay for Robot Manipulation Tasks

Erdi Sayar, Giovanni Iacca, Alois Knoll
Genetic and Evolutionary Computation Conference (GECCO), Melbourne, 2024
Combines multi-objective evolutionary search (NSGA-II) with hindsight experience replay to optimize value prediction, goal-proximity potential, and Wasserstein distance under obstacle constraints.
EuroGP '24 HER with Evolutionary Decision Trees

Hindsight Experience Replay with Evolutionary Decision Trees for Curriculum Goal Generation

Erdi Sayar, Vladislav Vintaykin, Giovanni Iacca, Alois Knoll
EvoApplications / EuroGP (Springer LNCS Vol. 14634), 2024
Evolves interpretable binary decision trees via Grammatical Evolution and continuously refines waypoints using critic Q-value feedback for sparse-reward manipulation.
GECCO '22 Exploration of unknown environments

Exploration of Unknown Environments via Evolution of Behavioral and Morphological Properties of Miniaturized Sensory Agents

Cagatay Sariman, Ahmed Hallawa, Erdi Sayar, Arne Peine, Lukas Martin, Anke Schmeink
ACM Genetic and Evolutionary Computation Conference (GECCO), Boston, 2022
Evolutionary co-design of physical morphologies and distributed behaviors for autonomous miniaturized sensor swarms exploring unstructured spaces.

Projects

Open-source research systems & frameworks.

Diffusion Curriculum RL

PyTorch framework utilizing conditional diffusion models to synthesize adaptive curricula for sparse-reward manipulation.

PyTorch Diffusion MuJoCo
View Code

Mobile Manipulator Control

Hierarchical optimization and coordinated motion planning framework for redundant high-DOF mobile manipulators.

ROS C++ MuJoCo
View Code

Hindsight Prioritization

Tactile and contact-energy prioritized replay buffer baselines on Fetch and Franka Emika Panda benchmarks.

Reinforcement Learning Franka HER
View Code

Experience

Academic appointments & research positions.

Postdoctoral Researcher

09/2025 – Present
Paderborn, Germany
  • Research in reinforcement learning, vision-language-action (VLA) models, and safe Generative AI for robotics.
  • Teaching: Advanced System Theory and Nonlinear Control of Autonomous Systems.

Research Associate / Doctoral Researcher

10/2020 – 08/2025
Munich, Germany
  • Doctoral research on reinforcement learning, diffusion models, and curriculum learning for robot manipulation.
  • Teaching: Lecturer and exercise lead for Kognitive Systeme (IN2222), Summer 2023 & 2024.

Student Assistant

10/2018 – 04/2019
Aachen, Germany
  • Research on anomaly detection in unknown environments using miniaturized sensory swarm agents.

Research Assistant

02/2017 – 02/2018
Izmir, Türkiye
  • Teaching assistant for ME352 System Analysis and Control & ME242 Applied Mathematics for Engineers.

Research Assistant

02/2016 – 02/2017
Istanbul, Türkiye
  • Research on quantitative methods and industrial automation control systems.

Service & Mentoring

Conference organization, workshops, and student mentorship.

Special Session Organizer · IEEE WCCI 2026

"Generative Foundation Models for Robotics: From Language and Vision to Embodied Action" at IEEE World Congress on Computational Intelligence.
Visit Workshop Website →

Summer School Co-Organizer · IEEE CIS 2025

"Foundational Models Meet Robotics: From Language and Vision to Action" IEEE CIS Summer School at Paderborn University.
Visit Summer School Website →

Student Thesis Mentoring at TUM

M.Sc. Students Supervised: Md Siyam Sajeeb Khan, Xiyuan Wang, Efe Kaya, Faruk Oruc, İlker Ayçiçek, Alexander Höhn, Ramandika Pranamulia.
Undergraduate Students: Vladislav Vintaykin, Khalil Chikhaoui, Emre Öztas, Mohamed Bouhali, John F. Stewardson.

Contact

Get in touch for collaborations or research inquiries.

Location

Universität Paderborn
Warburger Str. 100, 33098 Paderborn, Germany

BibTeX copied to clipboard!